Robot
Components
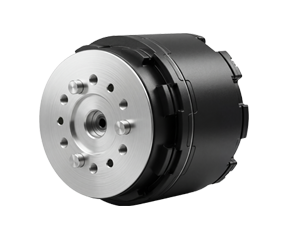
Bionic Robot Joint Motor
Small Size Giant power
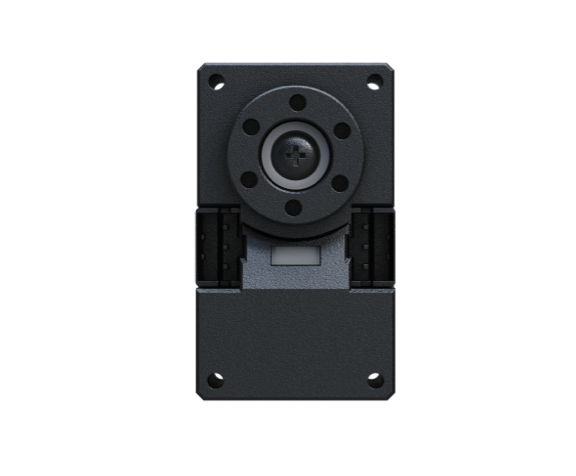
Brushless Digital Servo
Compact and Designed for Embodied Intelligence Applications
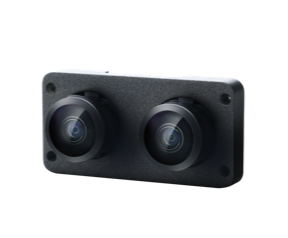
SV1-25
Embodied Stereo Binocular Camera
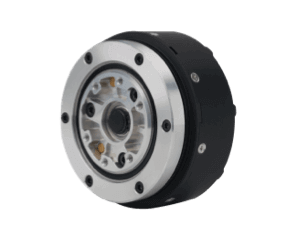
A1 Motor
Stable and Efficient with Hardcore Strength
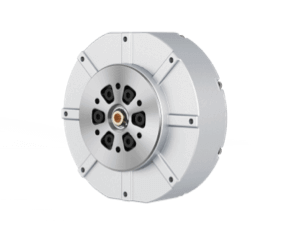
GO-M8010-6
Bionic Robot Joint Motor
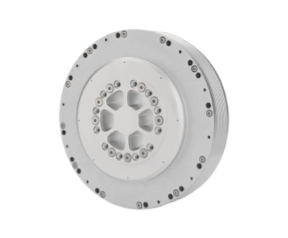
Super Robot Waterproof Joints B1-16
IP68 Industrial Waterproof, Long-term Operation
Accessory
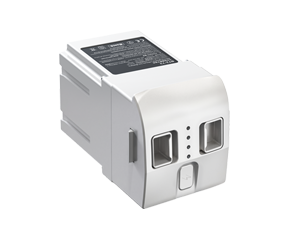
R1 Battery
Fast charging, powerful discharging
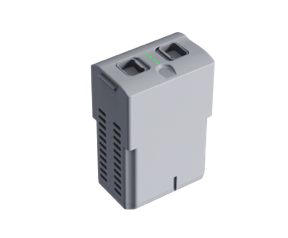
Go2 Battery
Fast Charging, Long-lasting Standby
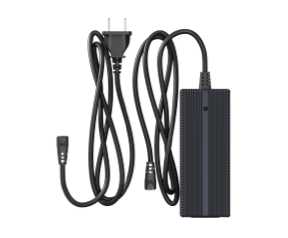
Go2 Charger
High Security Protection, Fast Charging
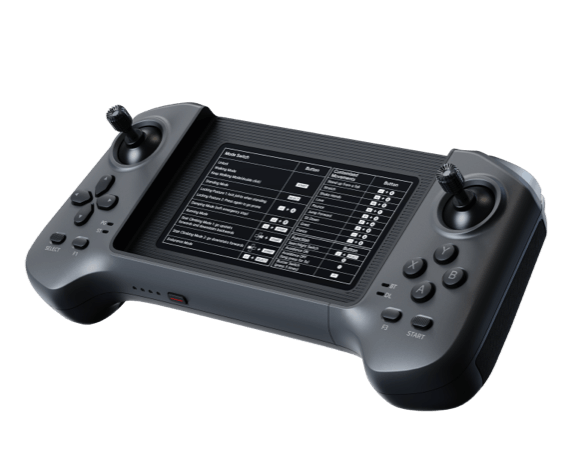
R3 Controller
Newly Upgraded, Immersive Interaction
Go2 Foot End
Sense-sensitive, Reliable and Durable
Go1 Battery
Fast Charging, Long-lasting Standby
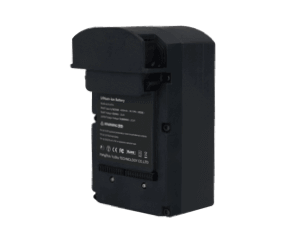
A1 Battery
Strong Power, Extraordinary Performance
Aliengo Battery
Excellent Motivation, Unlimited Ability
Industrial Applications
Services And Support
About Unitree
APP Download
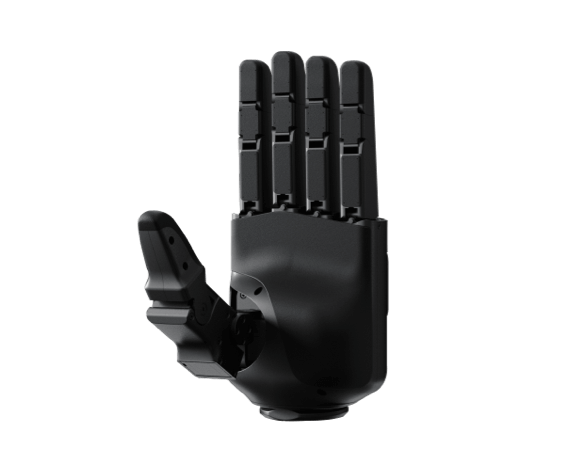
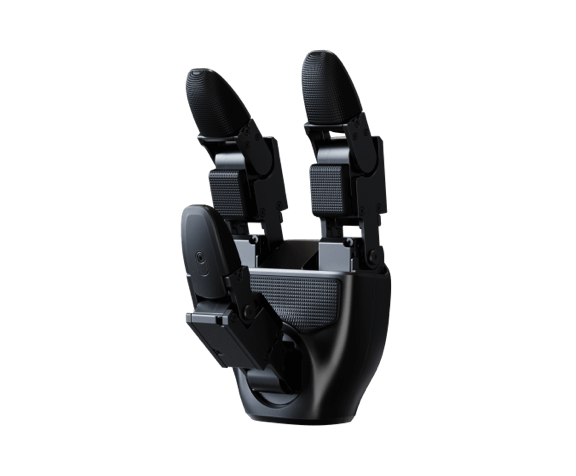
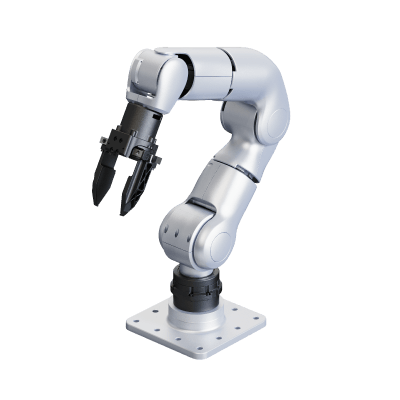
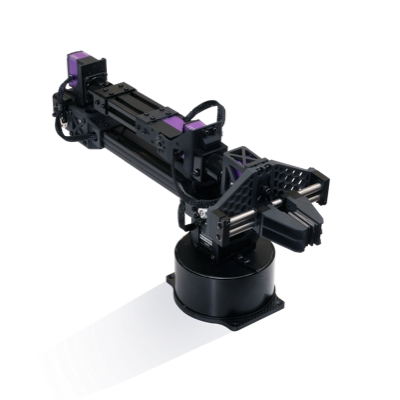
Brushless Digital Servo
Compact and Designed for Embodied Intelligence Applications
- Brushless Motor
Long Life, Low Inertia, High Speed, Force Control
- Temperature and Position Sensors
- Precision Gearbox (Backdrivable)
- Highly Integrated
- High Power, High Speed
- High-Speed Communication
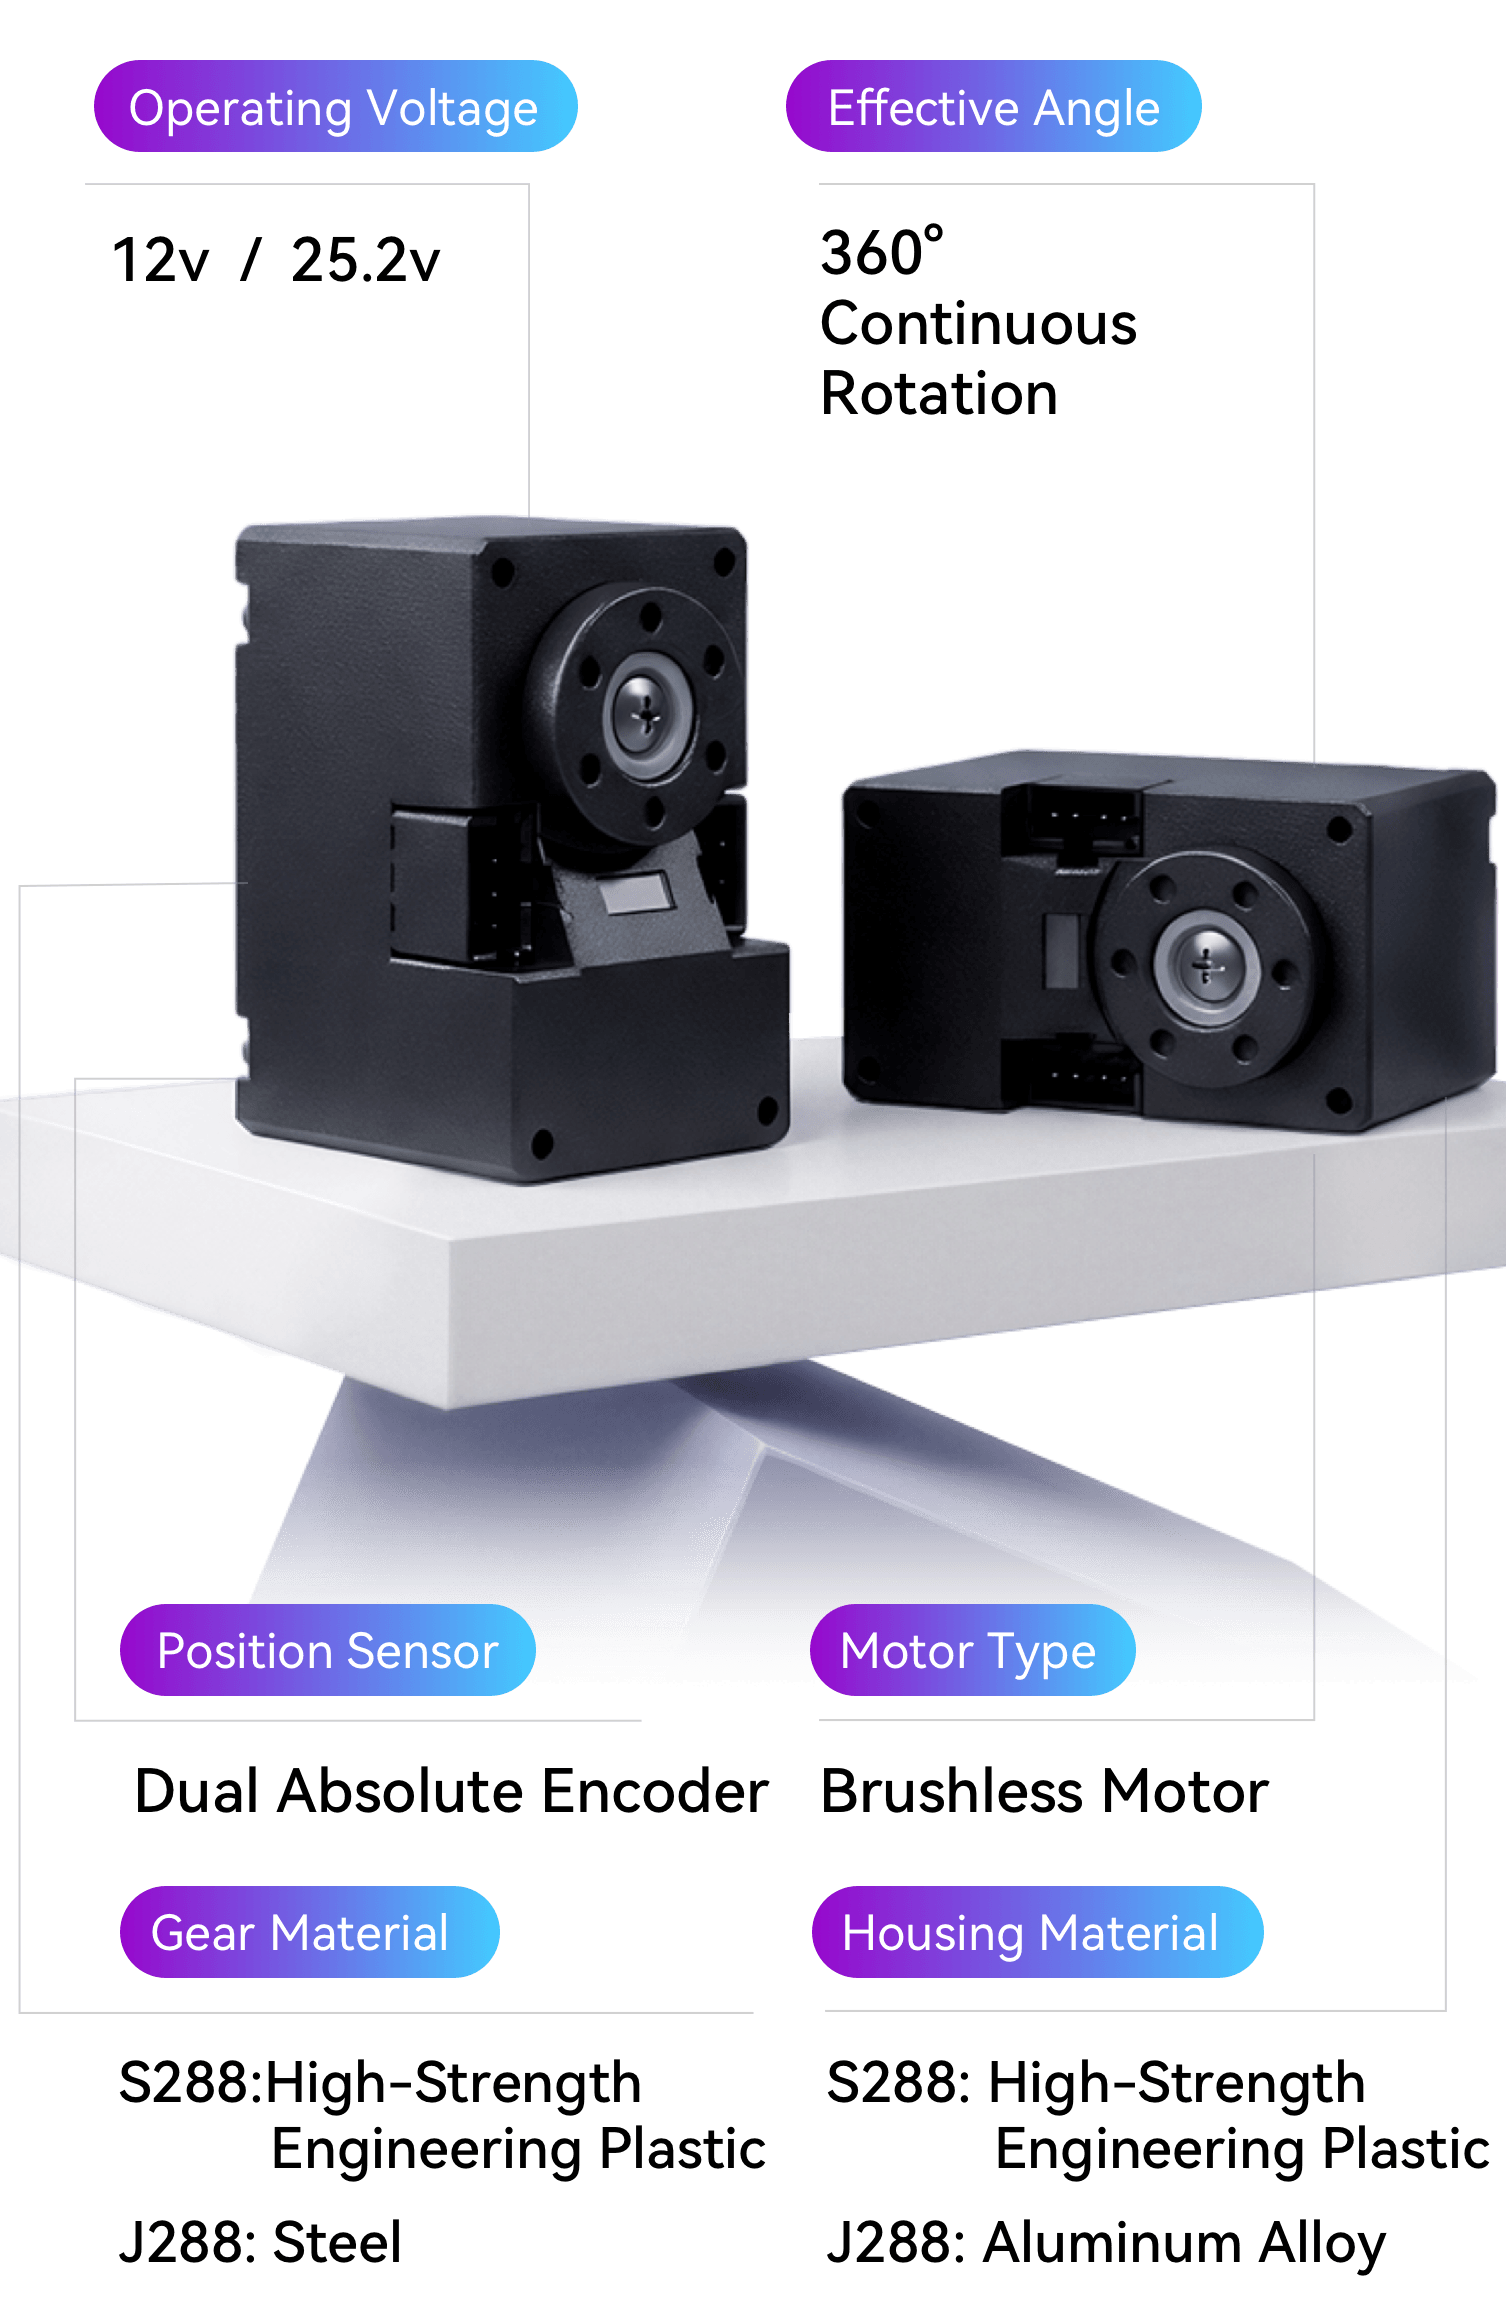
Model
Max (Stall) Torque
Torque Opposite to Speed Direction
Baud Rate
Max (No-Load) Speed
No-Load Current
 J288
1.5Nm
J2886,000,000bps
J28835rad/s (334rpm)@25.2V
/
16.5rad/s (157rpm)@12V
J2880.45A@25.2V 0.27A@12V
- S288
0.6Nm
S2886,000,000bps
S28816.5rad/s
(157rpm)@12V
S2880.27A@12V


Angle Control
Resolution: 8192 Steps, Continuous Rotation Without Angle Limit


Motor Feedback
Rotor Torque, Rotor Angle, Output Angle, Rotor Angular Velocity, Temperature, Voltage, Error Status


Operation Modes
Hybrid Mode: Rotor Torque, Rotor Angle, Rotor Angular Velocity, Rotor Stiffness, Rotor Damping

DIY Creation
Scientific Research and Education
Robot Competitions
Motion Joints

Front Fixing Diagram

Back Fixing Diagram
- YS-342026-S288
- YS-342026-J288
Input Voltage
Min.
6.4V
Recommended
12.6V
Max.
12.6V
Performance Characteristics
Voltage
12.6V
No-Load Current
0.27A@12V
Maximum (No-Load) Speed
16.5rad/s
Torque Constant
0.554Nm/A
Maximum (Stall) Torque
The Toque Is In The Opposite Direction of The Rotational Speed: 0.6Nm
Operating Temperature
Min.
-20℃
Max.
The driver board shuts down and reports an overheat error when exceeding 90 degrees
The winding shuts down and reports an overheat error when exceeding 120 degrees
Others
Position Sensor
Rotor, output end, dual absolute value encoder
Motor
Brushless Motor
Baud Rate
6,000,000bps
Control Algorithm
Hybrid Control
Gear Type
Spur Gear
Gear Material
Engineering Plastic
Shell Material
Engineering Plastic
Dimensions (W x H x D)
20 x 34 x 26mm
Weight
19.5g
Gear Ratio
288.35:1
Command Signal
Digital data packet
Rotor End Encoder Resolution
15bit
Protocol Type
Half-duplex asynchronous serial communication
(8bit, 1stop, No Parity)
Connection (Physical)
TTL level multi-point bus
ID
0-14
Motor Sensing Feedback
Rotor torque, Rotor angle, Output end angle, Rotor angular velocity, Temperature, Voltage, Error status
Protocol Version
Unitree Custom Protocol
Operating Mode / Angle
Hybrid mode: Rotor torque, Rotor angle, Rotor angular velocity, Rotor stiffness, Rotor damping
Standby Current [mA]
0.05A@12V
This product is a civilian robot. We kindly request that all users refrain from making any dangerous modifications or using the robot in a hazardous manner.
Please visit Unitree Robotics Website for more related terms and policies, and comply with local laws and regulations.