Unitree H2 Series Dual‑Arm Humanoid Robot
Redefining Industrial Mobile Manipulation

From Research Labs to Production Lines

Accelerating the Large-Scale Deployment of Humanoid Robotics

Product Portfolio
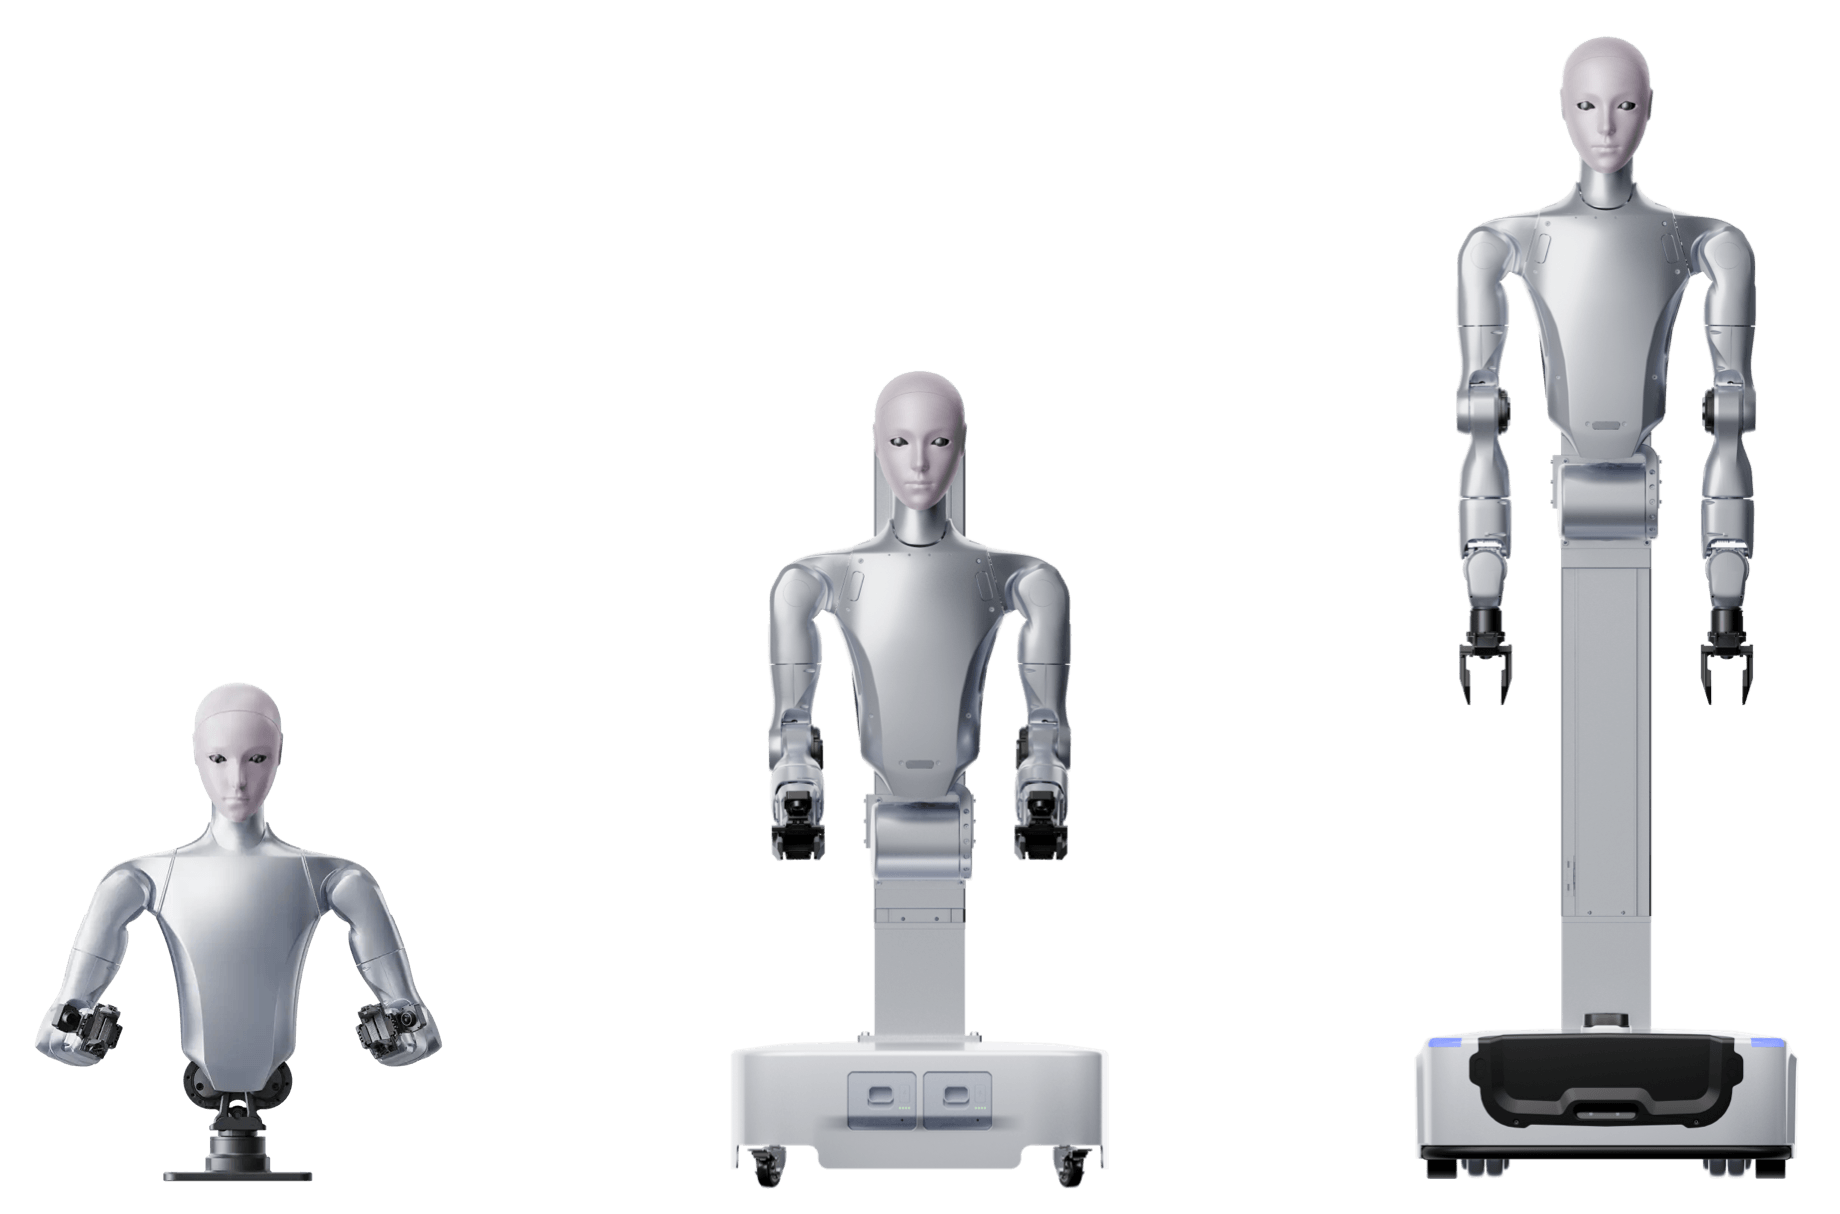
The Unitree H2 Series Dual-Arm Humanoid Robot includes two product lines: H2-D and H2-A, designed to support diverse deployment configurations for industrial operations, commercial services, research and development, and embodied intelligence training.
  • H2-A Standard
    Fixed Base
  • H2-D Standard
    Manual-Move Chassis
  • H2-D Flagship
    Mobile Chassis
High-Performance Embodied AI Platform
  • Fully In-House Technology Stack

    From self-developed actuators and force-controlled joints to motion control algorithms, H2-D features an in-house technology stack with tightly integrated hardware and software. Supports secondary development and system customization for rapid deployment across industrial, commercial, and research applications.

  • Multi-DOF Agile Motion

    Featuring multiple highly integrated force-controlled joints, H2-D supports omnidirectional mobility, vertical lift, and body pitch while maintaining outstanding stability and mobility in confined and complex environments.

  • Multimodal Perception

    Integrates vision, LiDAR, ultrasonic sensing, force feedback, and voice interaction to build a multimodal perception system, enabling intelligent environmental awareness and natural human–robot interaction.

Biomimetic Design & Full-Body Mobility

Total DOF (Excl. End-Effector)

  • H2-A Standard

    19

    Dual arms 7*2 + Waist 3 + Head 2

    Waist DOF: Pitch, Yaw, Roll

  • H2-D Standard

    19

    Dual arms 7*2 + Waist 1 + Head 2 + Lift Column 2

    Waist DOF: Pitch

    Column DOF: Vertical Lift, Yaw

  • H2-D Flagship

    20

    Dual arms 7*2 + Waist 1 + Head 2 + Column 1 + Chassis 2

    Waist DOF: Pitch

    Column DOF: Vertical Lift

Mechanical Performance & Flexible Deployment
  • Peak Payload: ~15 kg

    Rated Payload: ~7 kg

    Supports a rated payload of up to 7 kg per arm, enabling efficient handling and assembly of heavy industrial components.

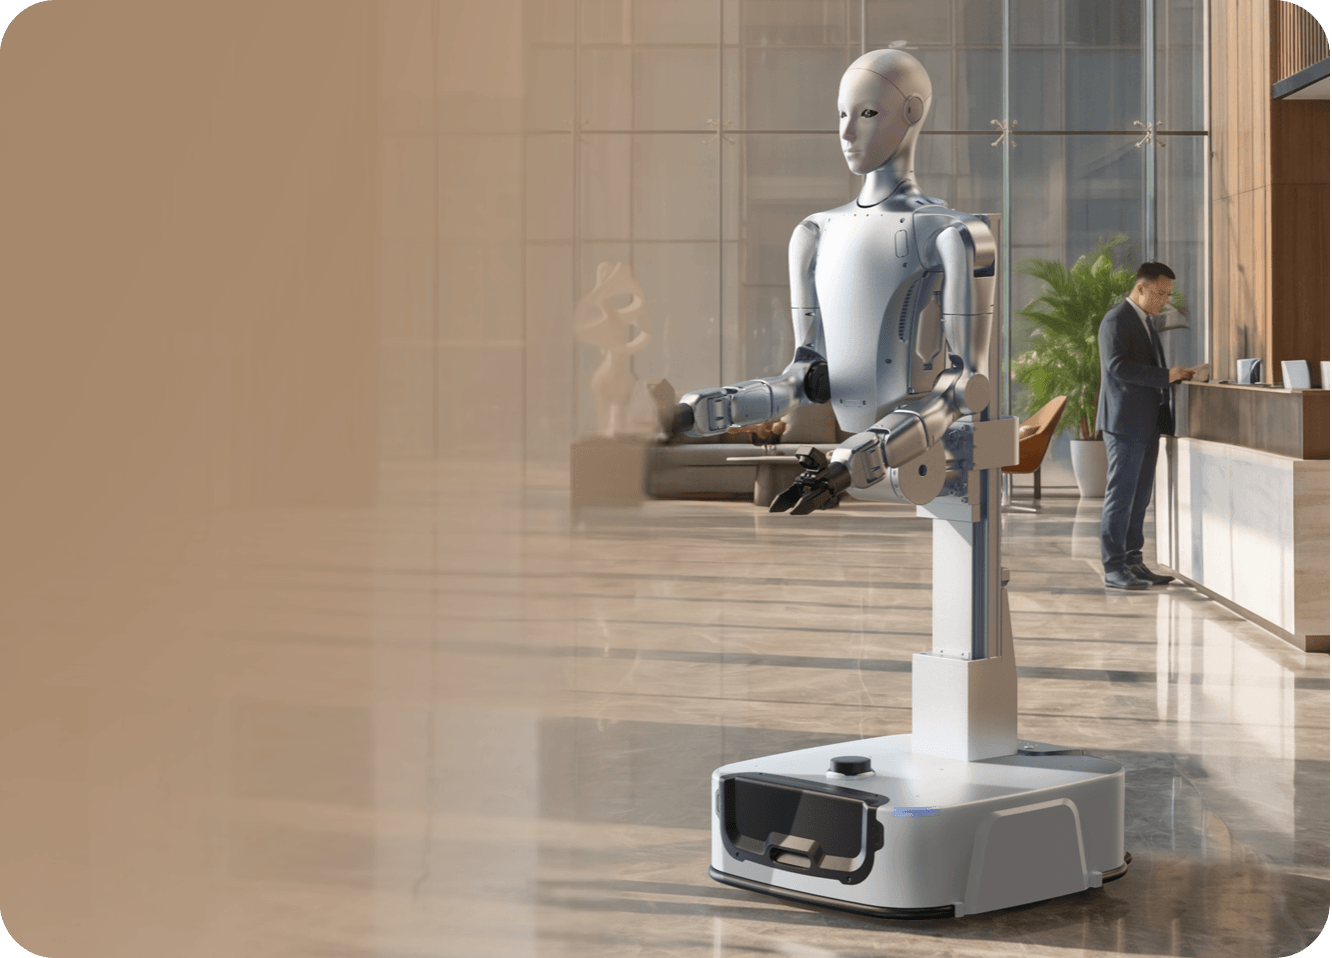
  • Fixed Base / Manual-Move Chassis / Mobile Chassis

    Configurable as either a precision workstation or a mobile manipulation platform for diverse production environments.

Expanded Workspace & Flexible Reach
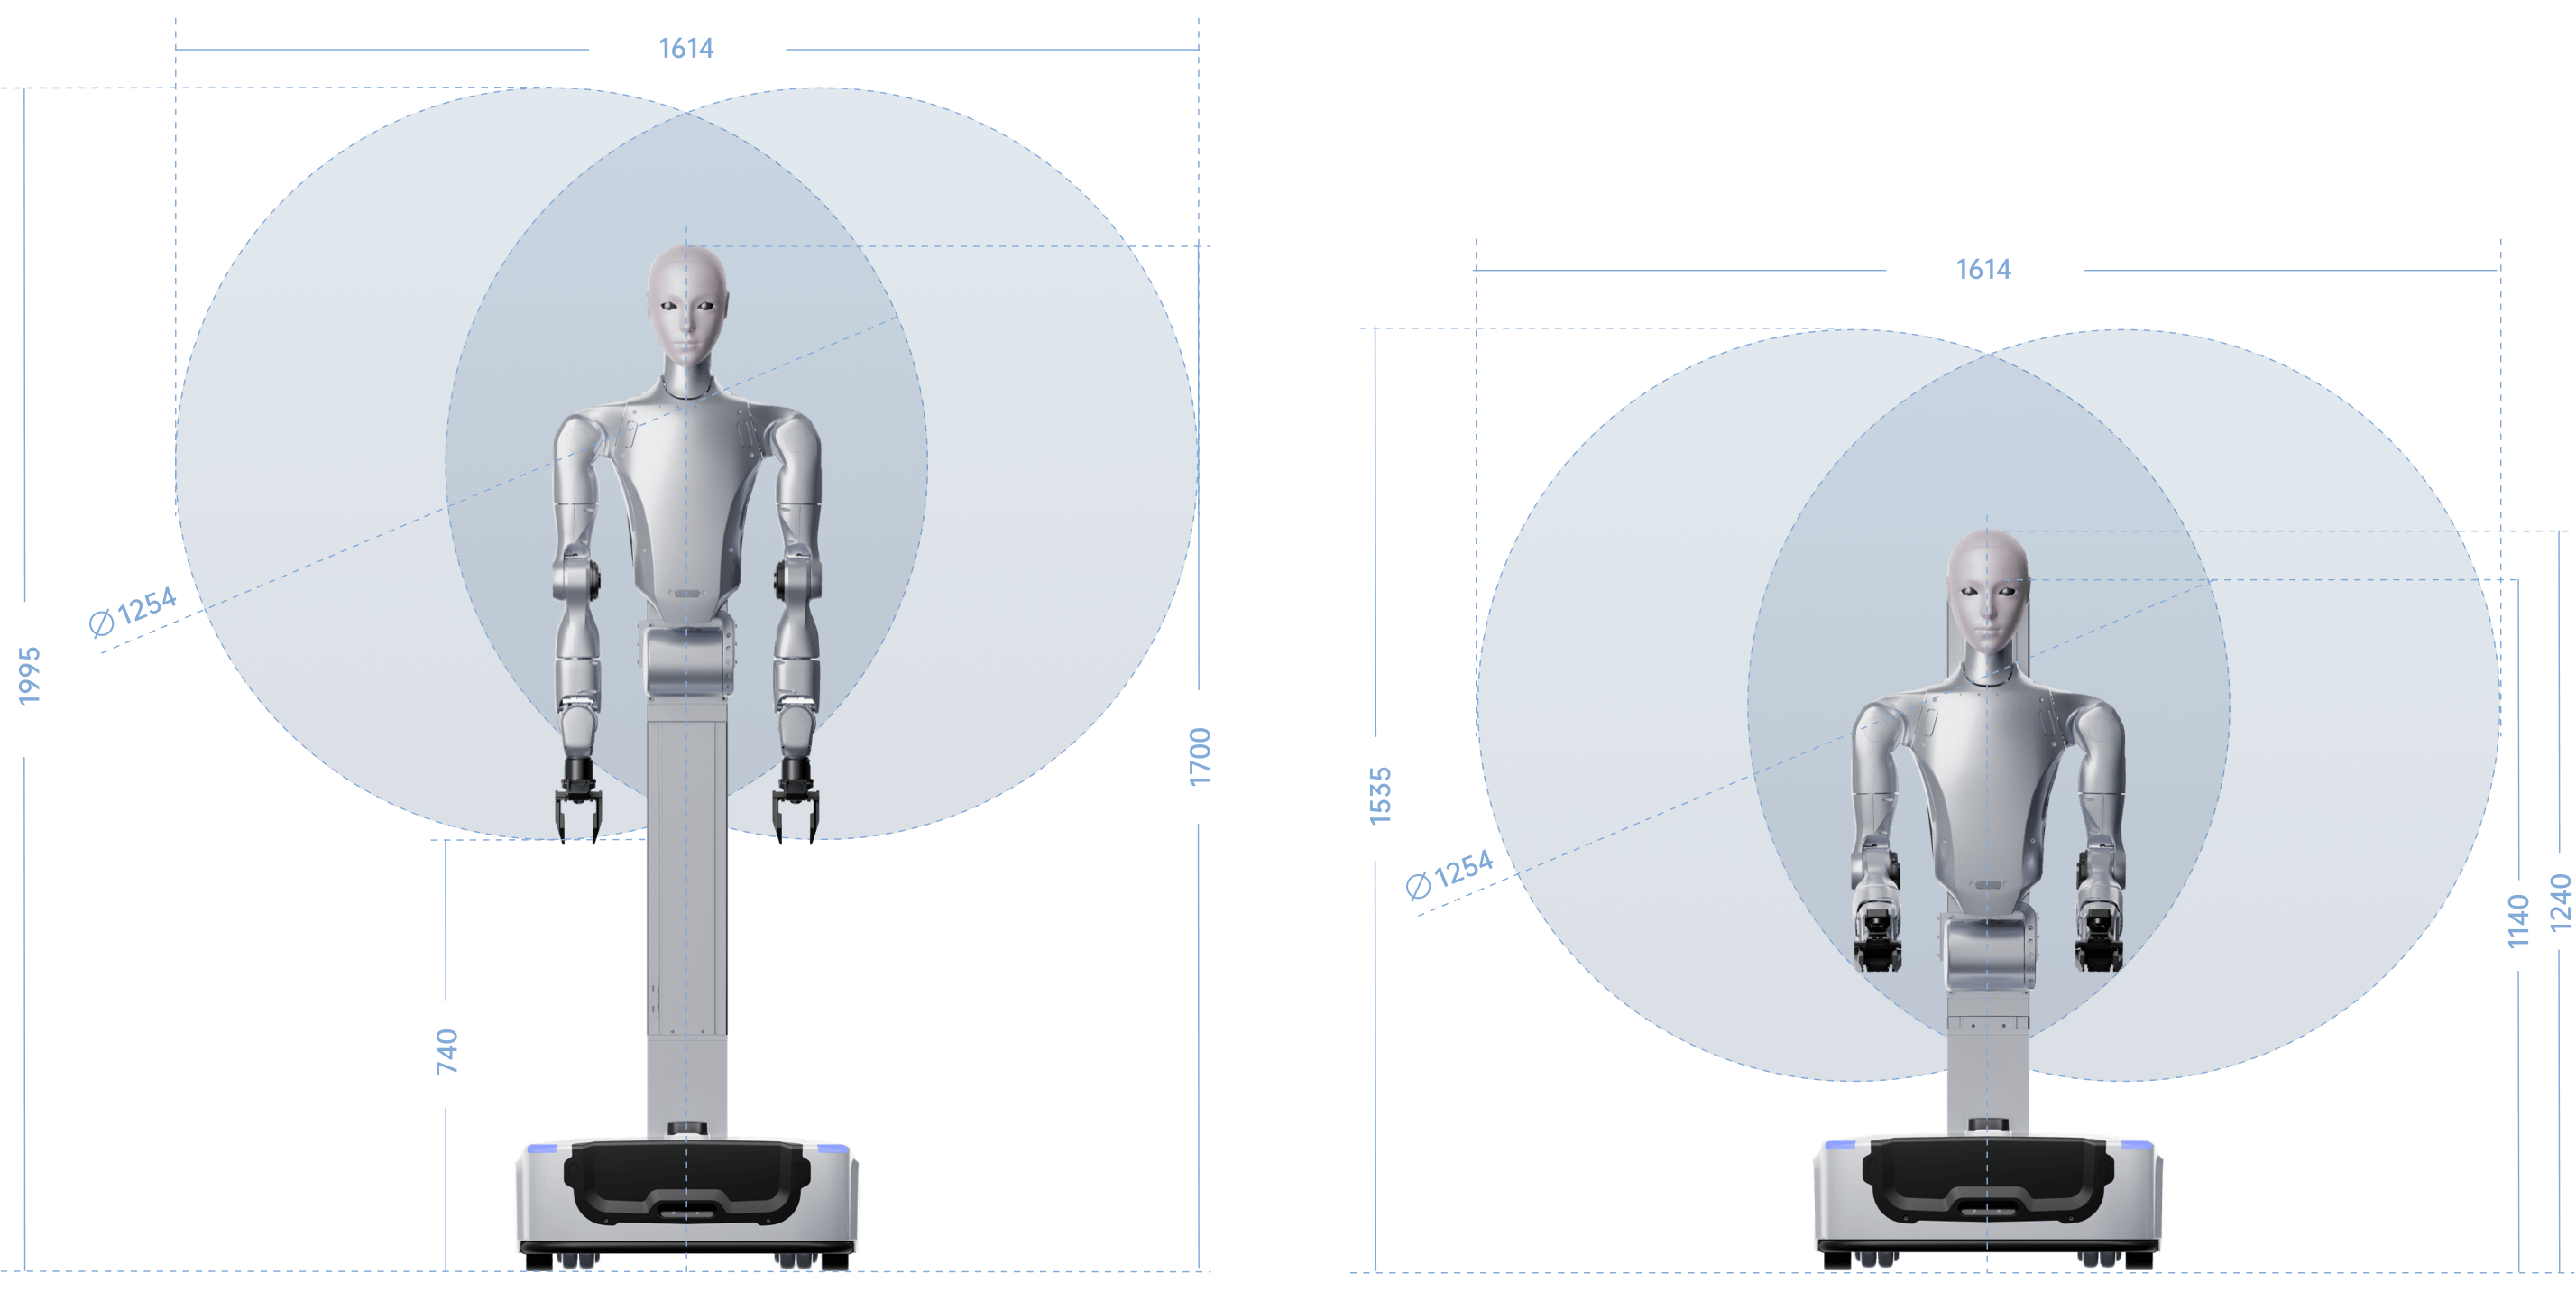
By utilizing waist pitch adjustment, column vertical lift, and whole‑body coordination algorithms, the robot's operational workspace is extended, enabling flexible manipulation within a height range from ground level up to 2 meters.
  • ~0.6 m

    Single-Arm Reach (Excl. Dexterity Hands)

  • 0.46m/0.36m

    Vertical Lift Travel

  • ~0.75 m

    Turning Diameter

  • 0-115°

    Waist Pitch Range

  • Flexible Posture with Agile Pitch Motion

    Supporting 0–115° body pitch, H2-D adapts to floor-level picking and overhead handling while providing a natural and ergonomic operating experience.

  • Multimodal Perception & Natural Interaction

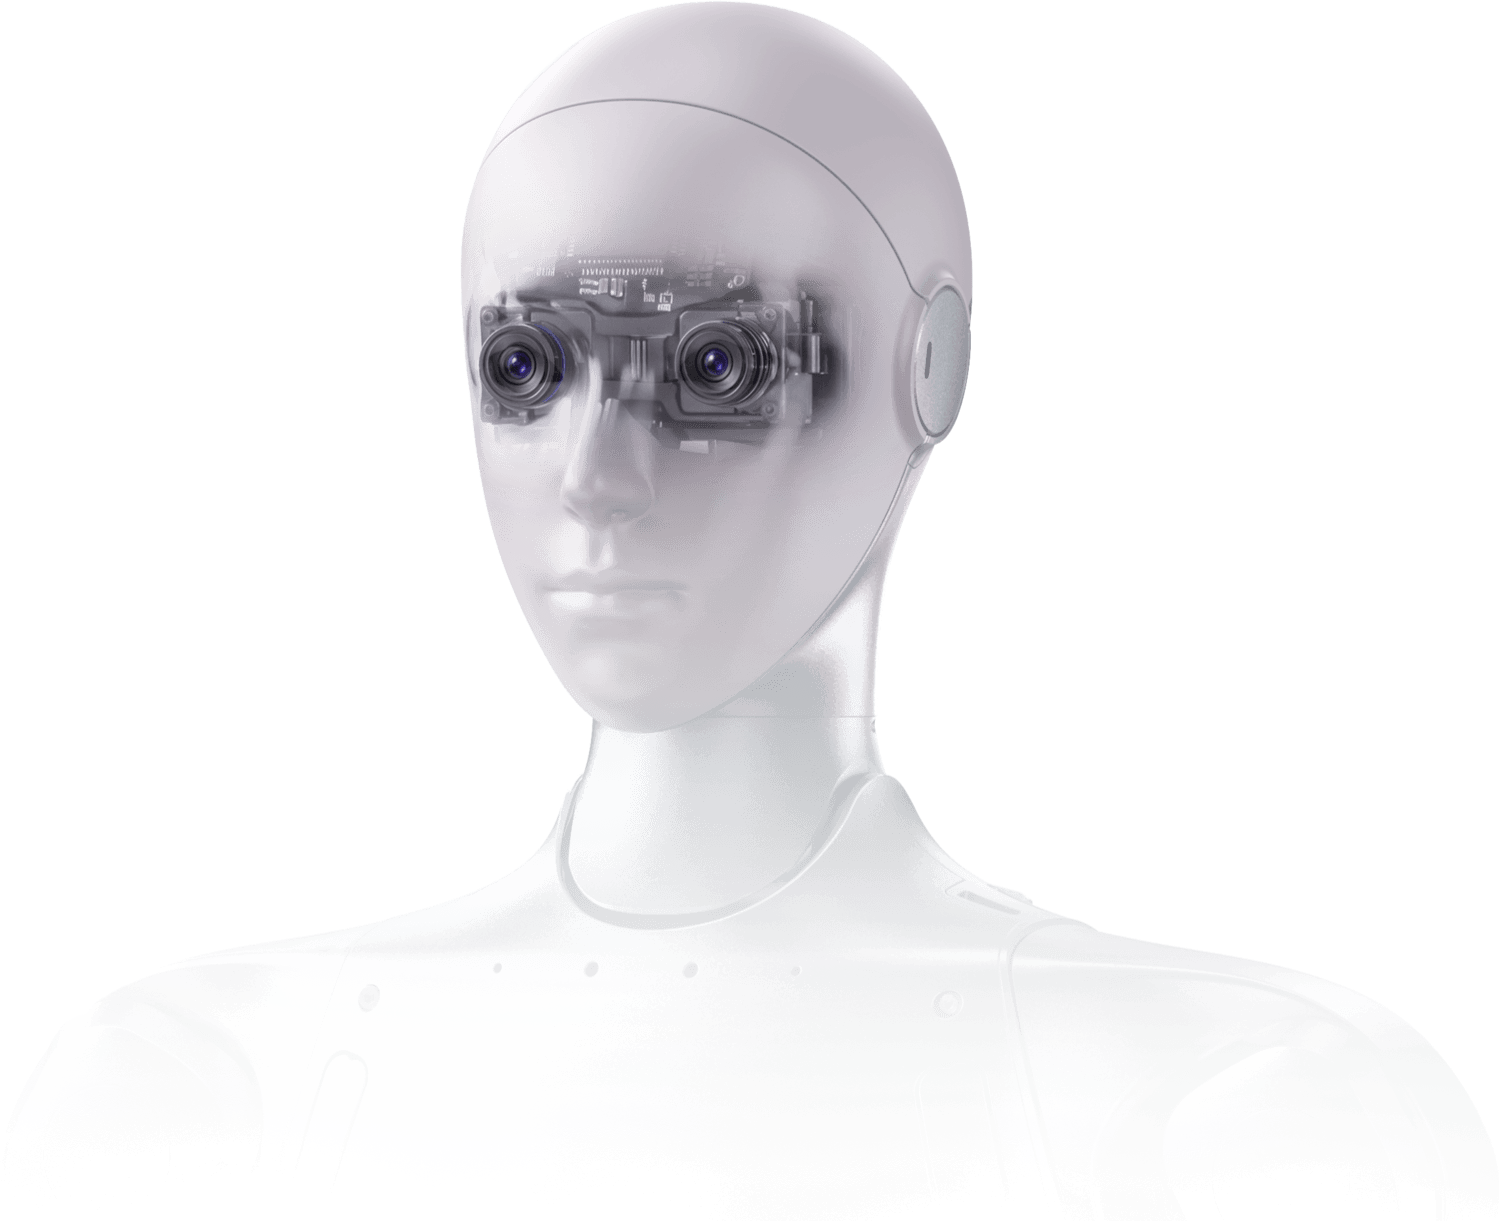
    Integrating binocular vision with natural language interaction, H2-D enables intuitive and natural human–robot collaboration.

  • Dynamic Operation with Proven Stability and Reliability

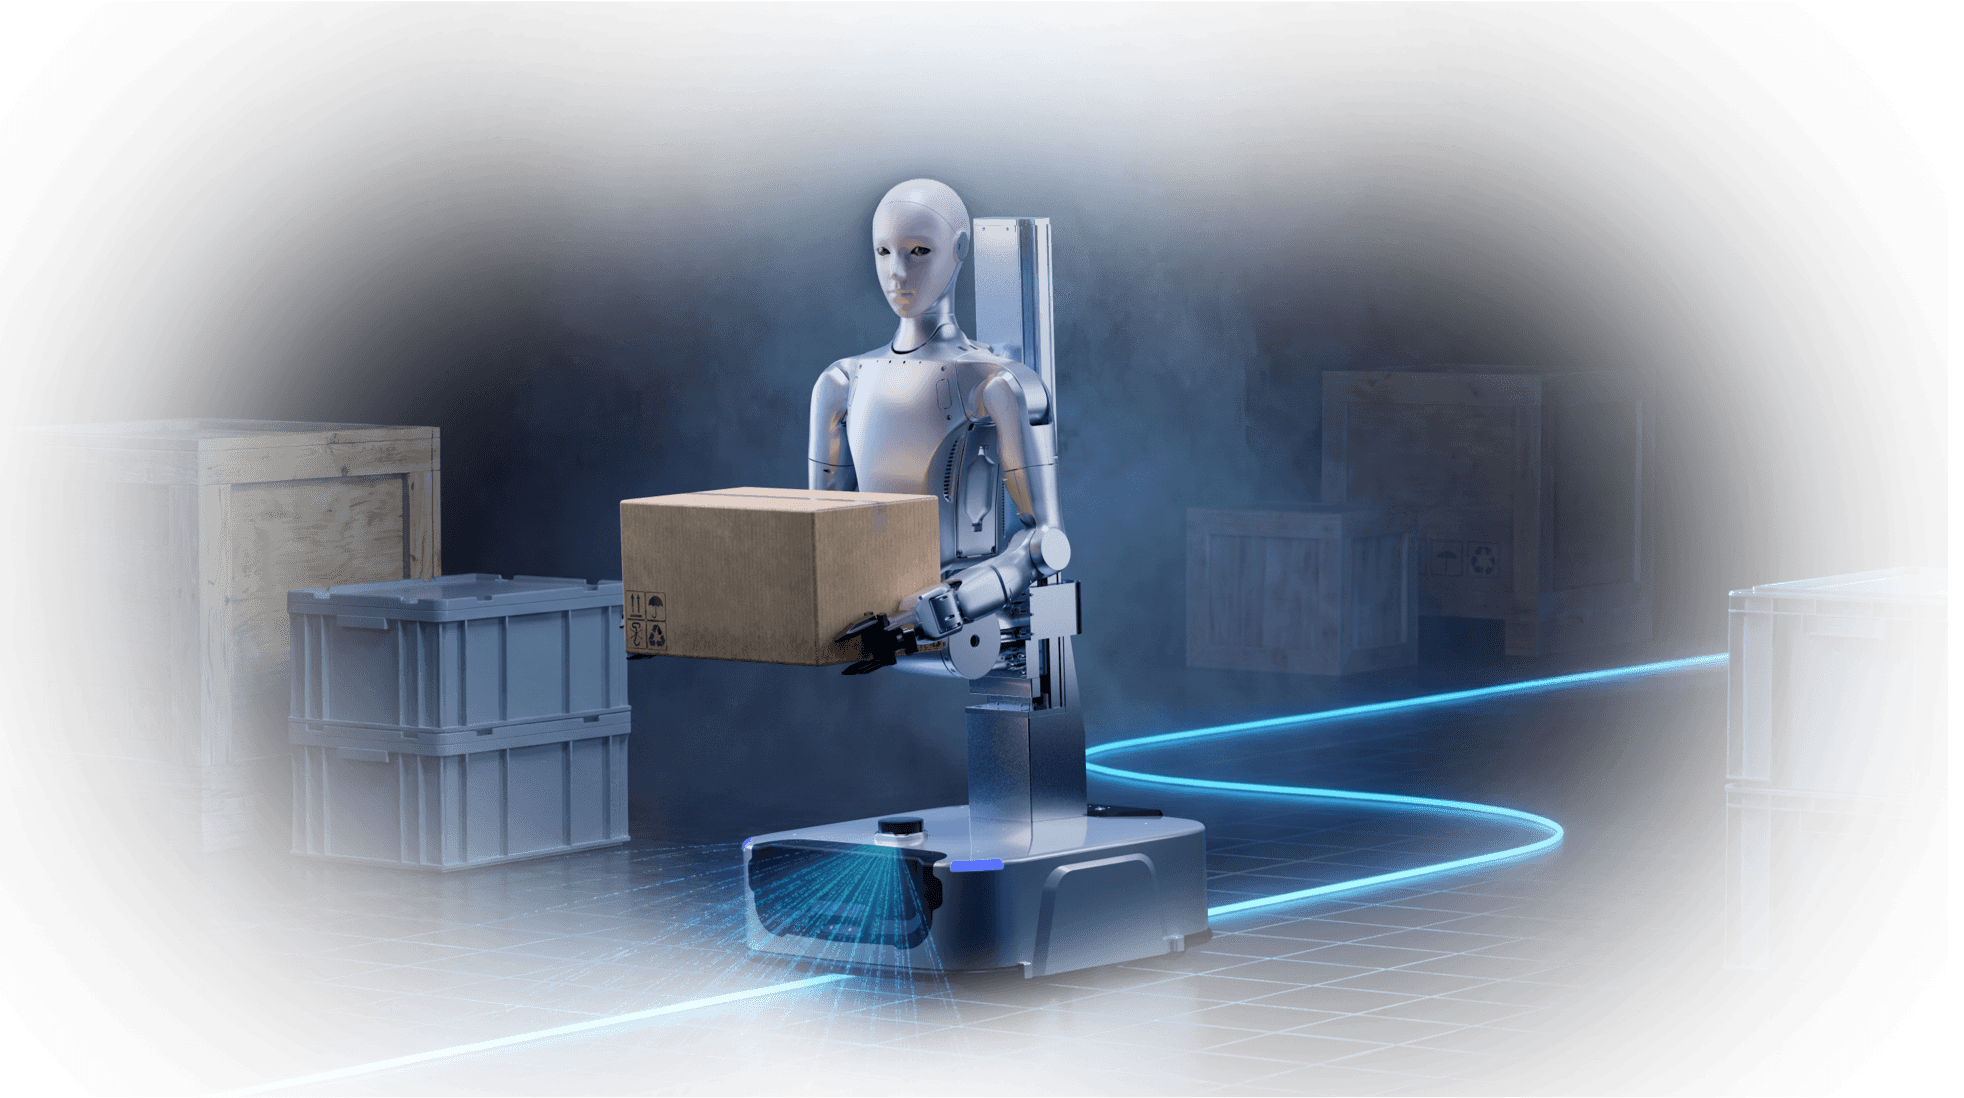
    The mobile platform integrates LiDAR, depth cameras, and multiple sensors to enable autonomous navigation and intelligent obstacle avoidance. Combined with high-performance joints and whole-body dynamics algorithms, H2 coordinates mobility, manipulation, and posture control to achieve precise operations in dynamic environments.

  • Multi-Type End Effectors & Flexible Adaptation

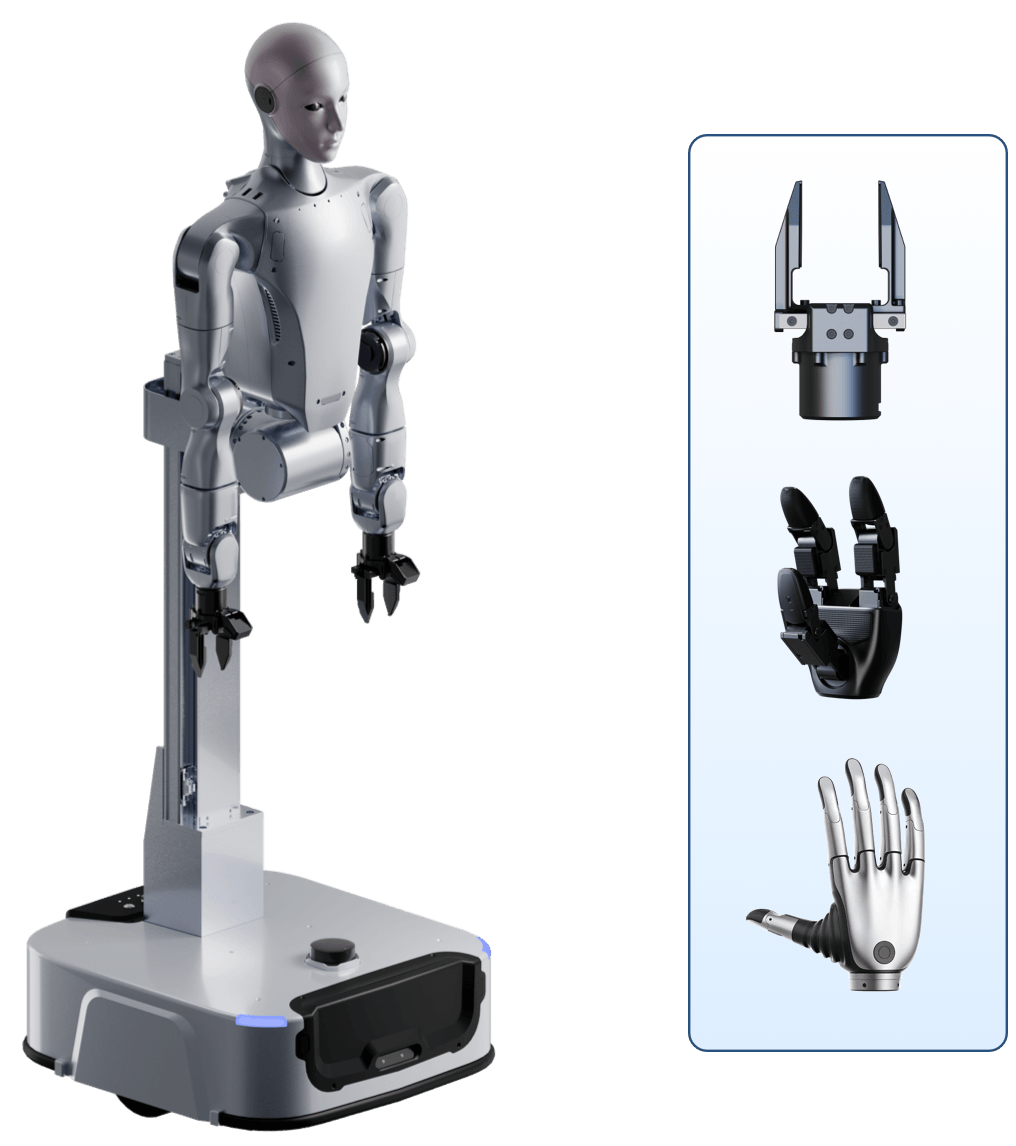
    Supports multiple end-effectors including: Grippers / Three-finger hands / Five-finger dexterous hands, Quick-change design enables rapid adaptation to different precision requirements and workload conditions.

  • Open Development & Rapid Deployment

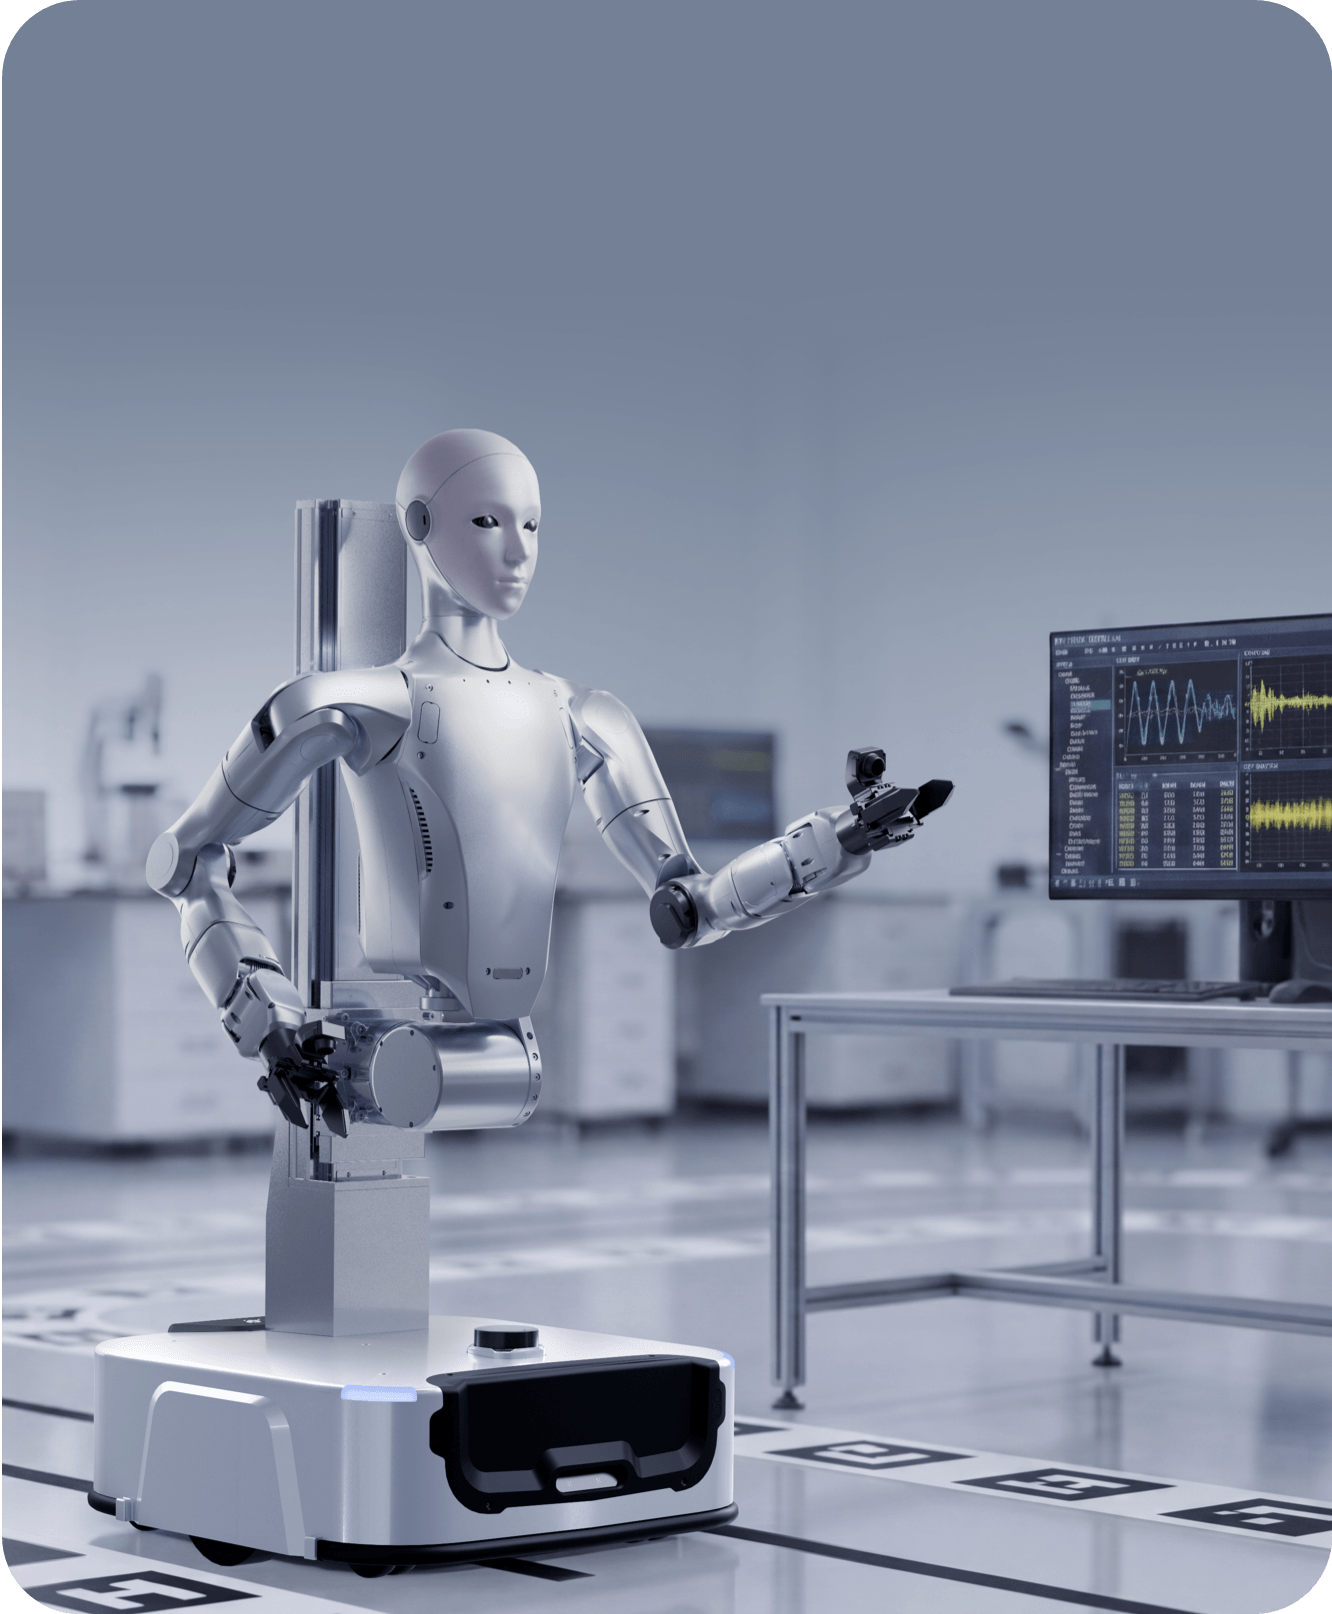
    Comprehensive SDKs and APIs, together with a mature navigation software stack, enable developers to focus on application innovation while reducing development cycles from months to weeks.

Applications
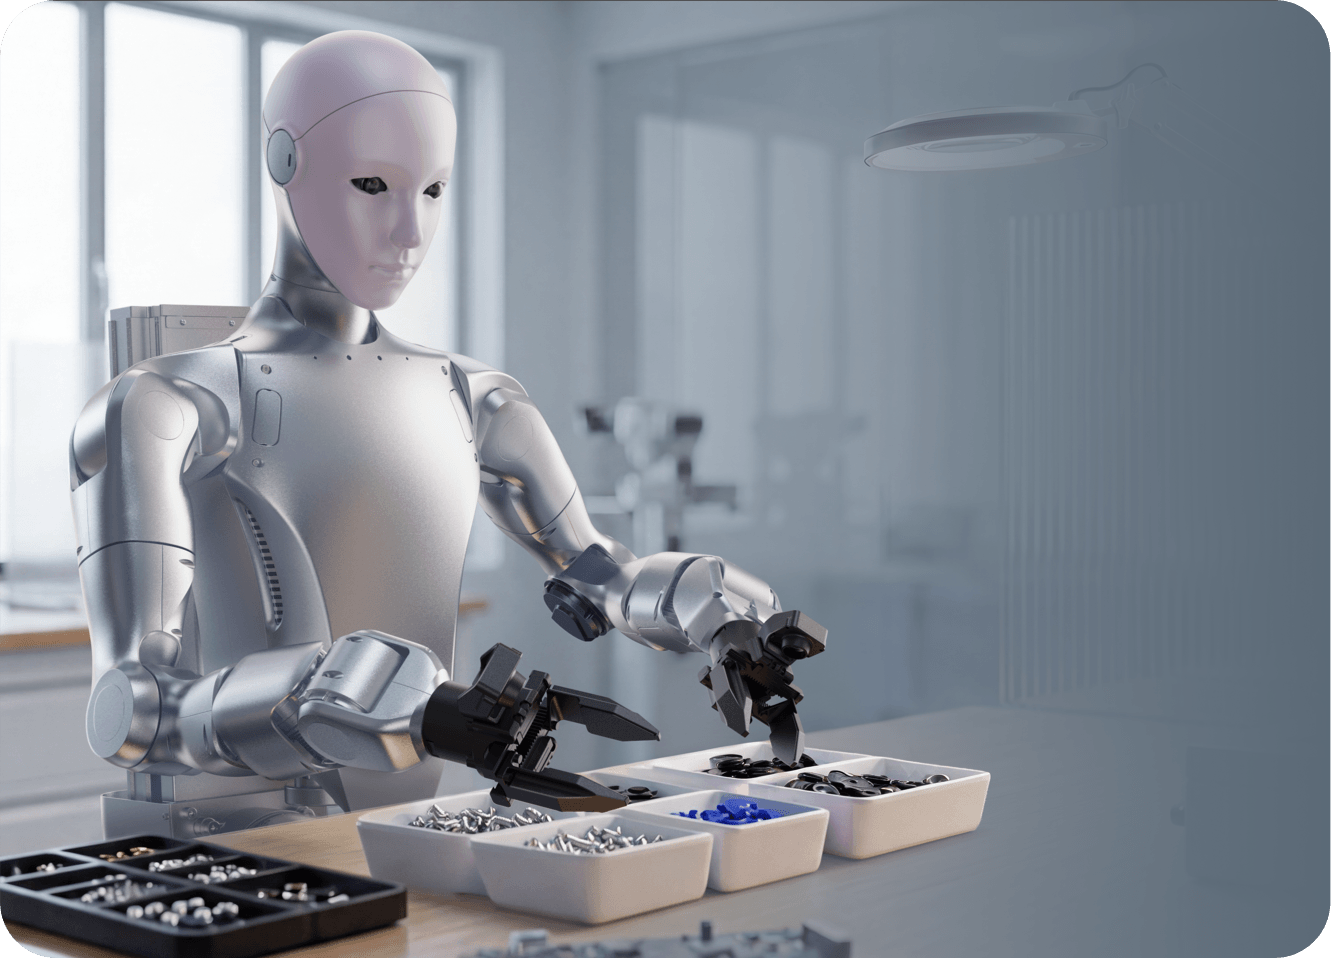
  • Industrial Automation

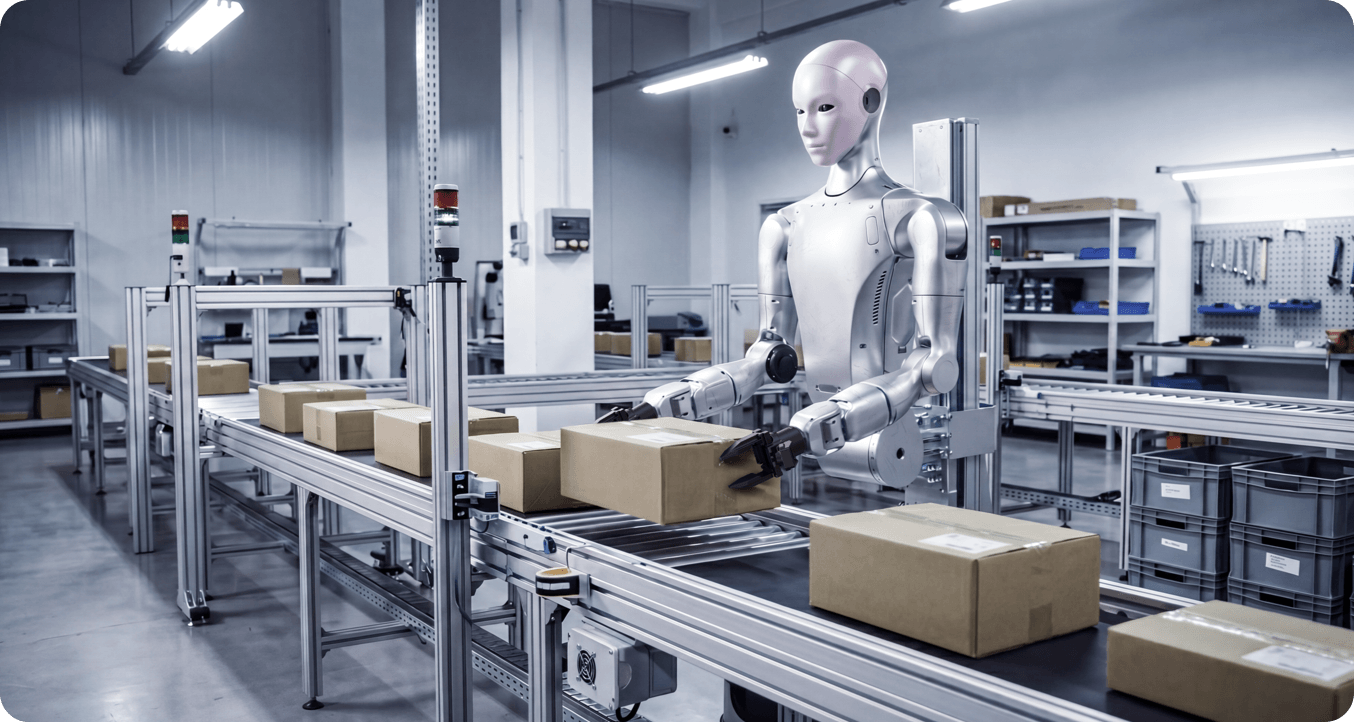
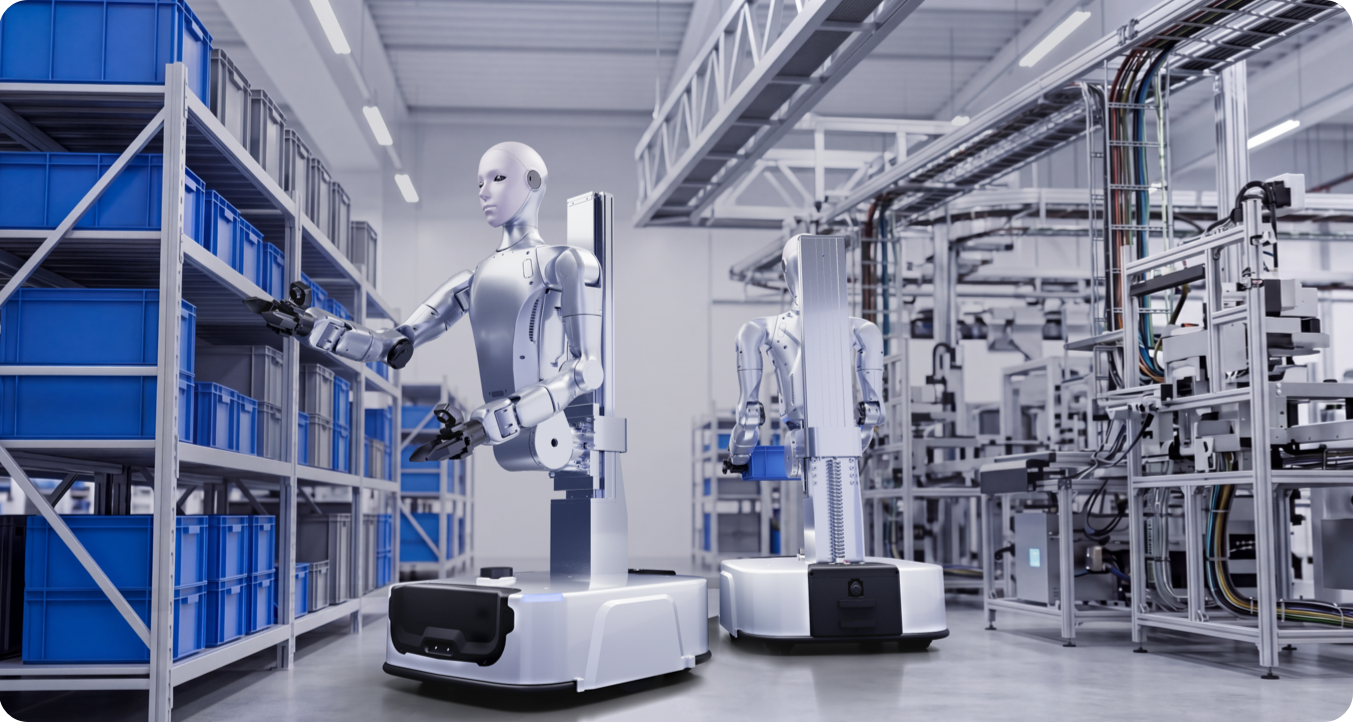
    Industrial automation, high-speed sorting, and autonomous warehousing.

  • Research & Education

    Embodied AI research and validation, robotics education and demonstrations.

  • Commercial Services

    Reception, guided tours, and retail operations.

  • Embodied AI Training Platform

    Large-scale real-world data collection, model fine-tuning, and sim-to-real transfer.

Product Parameters
Mechanical Dimensions
  • Model

    H2-A Standard

    H2-D Standard

    H2-D Flagship

  • Overall Dimensions 

    780x444x200mm

    Min. Column Height:1200x560x605mm

    Max. Column Height:1700x560x605mm

    Min. Column Height:1200x576x633mm

    Max. Column Height:1700x576x633mm

  • Total Weight (with Battery)

    33.5Kg

    Approx. 148Kg

    Approx. 120Kg

  • Total DOF (Excl. End-Effector)

    19

    19

    20

  • Arm DOF (Excl. End-Effector)

    7

    7

    7

  • Waist DOF

    3

    1

    1

  • Head DOF

    2

    2

    2

  • Column DOF

    /

    2

    1

  • Chassis DOF

    /

    /

    2

  • Joint Output Bearing

    Industrial‑Grade Cross‑Roller Bearing (High Precision, High Load‑Carrying Capacity)

    Industrial‑Grade Cross‑Roller Bearing (High Precision, High Load‑Carrying Capacity)

    Industrial‑Grade Cross‑Roller Bearing (High Precision, High Load‑Carrying Capacity)

  • Joint Motor

    Low-Inertia High-Speed Inner-Rotor Permanent Magnet Synchronous Motor(Enhanced Dynamic Response and Thermal Performance)

    Low-Inertia High-Speed Inner-Rotor Permanent Magnet Synchronous Motor(Enhanced Dynamic Response and Thermal Performance)

    Low-Inertia High-Speed Inner-Rotor Permanent Magnet Synchronous Motor(Enhanced Dynamic Response and Thermal Performance)

  • Maximum Arm Joint Torque

    120N.M

    120N.M

    120N.M

  • Maximum Arm Payload [1]

    Peak: ~15 kg

    Rated: ~7 kg

    Peak: ~15 kg

    Rated: ~7 kg

    Peak: ~15 kg

    Rated: ~7 kg

  • End-Effector Options [2]

    Optional 2-Finger Gripper / 3-Finger Dexterous Hand / 5-Finger Dexterous Hand

    Optional 2-Finger Gripper / 3-Finger Dexterous Hand / 5-Finger Dexterous Hand

    Optional 2-Finger Gripper / 3-Finger Dexterous Hand / 5-Finger Dexterous Hand

  • Waist Joint Range of Motion

    Yaw: ±155°

    Pitch:+25°/-30°

    Roll: ±30°

    Pitch:0°-115°

    Pitch:0°-115°

  • Lift Speed

    /

    Up to 200 mm/s

    Up to 200 mm/s

  • Lift Travel

    /

    0.36m

    0.46m

  • Single-Arm Reach (Excl. Dexterity Hands)

    ~0.6m

    ~0.6m

    ~0.6m

  • Overall Material Composition

    Aerospace-Grade Aluminum, Titanium Alloy, and High-Strength Engineering Plastics

    Aerospace-Grade Aluminum, Titanium Alloy, and High-Strength Engineering Plastics

    Aerospace-Grade Aluminum, Titanium Alloy, and High-Strength Engineering Plastics

Chassis Parameters
  • Maximum Mobility Speed

    /

    /

    Up to 1.5 m/s

  • Drive System

    /

    /

    Servo motors, dual-wheel differential drive, supports 360° in-place rotation

  • Turning Diameter

    /

    Supports ±90° in-place Z-axis rotation

    Turning diameter: ~0.75 m

  • Chassis Sensors

    /

    /

    LiDAR ×1

    Depth Camera ×1

    Physical Collision Sensor ×2

    Ultrasonic Sensor ×2

Electrical Characteristics
  • Cooling System

    Air Cooling

    Air Cooling

    Air Cooling

  • Base Computing

    PC1: Intel Core i5 (Platform Capabilities)

    PC2: Intel Core i7 (Custom Development)

    PC1: Intel Core i5 (Platform Capabilities)

    PC2: Intel Core i7 (Custom Development)

    PC1: Intel Core i5 (Platform Capabilities)

    PC2: Intel Core i7 (Custom Development)

  • Perception Sensors

    Humanoid Binocular Camera with Wide Field of View ×1

    Wrist HD Camera ×2

    Humanoid Binocular Camera with Wide Field of View ×1

    Wrist HD Camera ×2

    Humanoid Binocular Camera with Wide Field of View ×1

    Wrist HD Camera ×2

  • Voice Interaction

    Microphone Array & High-Power Speaker for Natural Voice Interaction

    Microphone Array & High-Power Speaker for Natural Voice Interaction

    Microphone Array & High-Power Speaker for Natural Voice Interaction

  • WiFi 6 & Bluetooth 5.2

    Yes

    Yes

    Yes

Accessories
  • High-Performance Computing Module

    Multiple brands and models available

    such as Thor, etc.

    Multiple brands and models available

    such as Thor, etc.

    Multiple brands and models available

    such as Thor, etc.

  • Battery

    Quick-Release Battery: 75.6V/15Ah(972Wh)

    Quick-Release Base Battery: 48V/18Ah (864Wh)

    Quick-Release Base Battery: 48V/30Ah (1.44 kWh)

  • Handheld Controller

    Yes

    Yes

    Yes

Other
  • Battery Life

    Battery Power Supply: Approx. 8h (Depending on Operating Conditions)

    Direct Power Supply: 7*24H

    Direct Power Supply: 7*24H

    Battery Power Supply: Approx. 5h (Replaceable Battery / Auto Charging)

  • Intelligent OTA Updates

    Yes

    Yes

    Yes

  • Secondary Development [3]

    Yes

    Yes

    Yes

  • Warranty

    12 Months

    12 Months

    12 Months

[1]

The maximum load of the arm varies greatly under different arm extension postures.

[2]

For end-effector selection, please contact our sales team.

[3]

For more information, please read the secondary development manual.

[4]

The above parameters may vary in different scenarios and configurations, please subject to actual situation.

[5]

The humanoid robot features a complex structure and extremely powerful power. Users must maintain a sufficient safety distance between humans and the robot. Use with extreme caution

[6]

The product appearance is subject to change. Please refer to the final product.

[7]

Some features are under development and will be released gradually.

This product is a civilian robot. We kindly request that all users refrain from making any dangerous modifications or using the robot in a hazardous manner.

Please visit Unitree Robotics Website for more related terms and policies, and comply with local laws and regulations.