Robot
Components
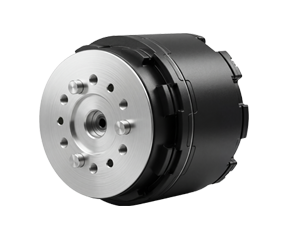
Bionic Robot Joint Motor
Small Size Giant power
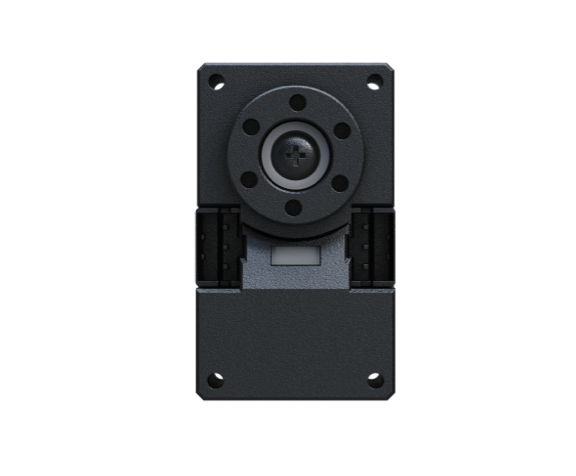
Brushless Digital Servo
Compact and Designed for Embodied Intelligence Applications
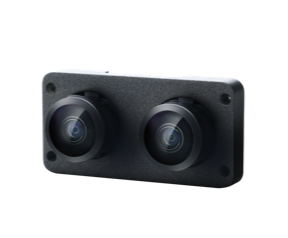
SV1-25
Embodied Stereo Binocular Camera
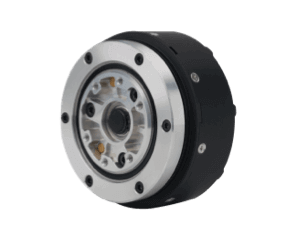
A1 Motor
Stable and Efficient with Hardcore Strength
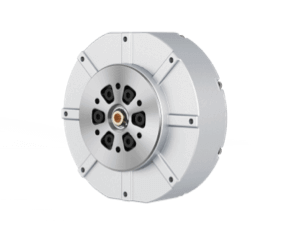
GO-M8010-6
Bionic Robot Joint Motor
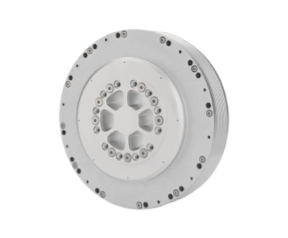
Super Robot Waterproof Joints B1-16
IP68 Industrial Waterproof, Long-term Operation
Accessory
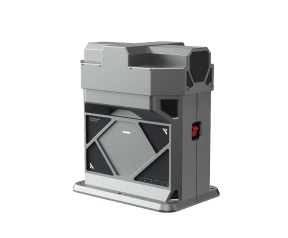
A2 Intelligent Autonomous Charging Dock
Precise Docking, Reliable Runtime
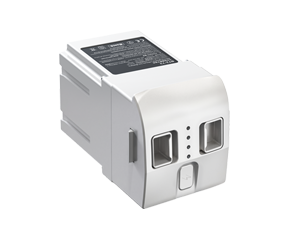
R1 Battery
Fast charging, powerful discharging
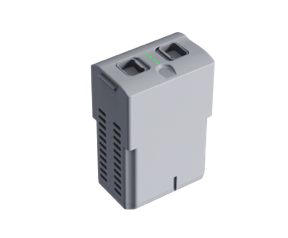
Go2 Battery
Fast Charging, Long-lasting Standby
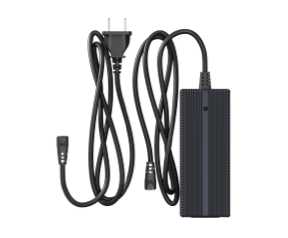
Go2 Charger
High Security Protection, Fast Charging
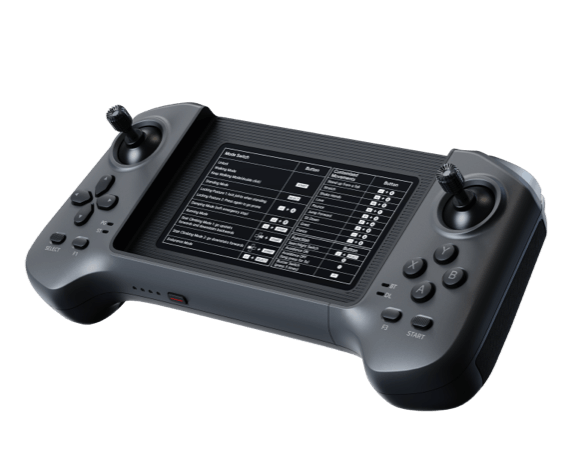
R3 Controller
Newly Upgraded, Immersive Interaction
Go2 Foot End
Sense-sensitive, Reliable and Durable
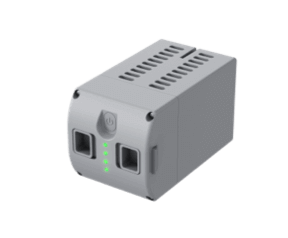
Go1 Battery
Fast Charging, Long-lasting Standby
A1 Battery
Strong Power, Extraordinary Performance
Aliengo Battery
Excellent Motivation, Unlimited Ability
Industrial Applications
Services And Support
About Unitree
APP Download
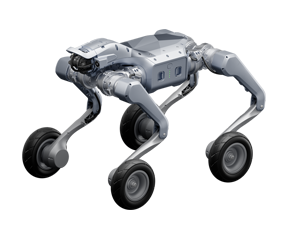
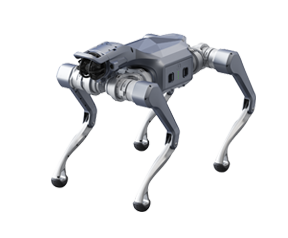
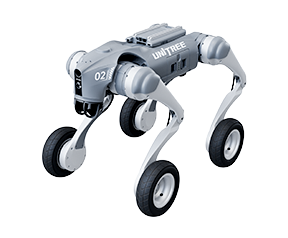
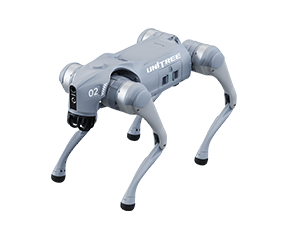
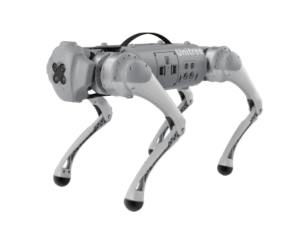
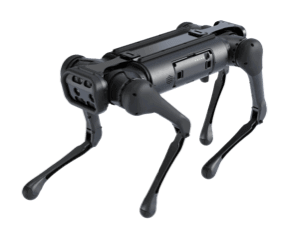
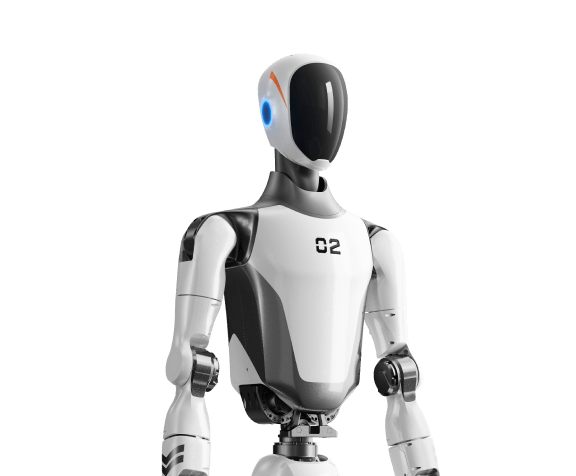
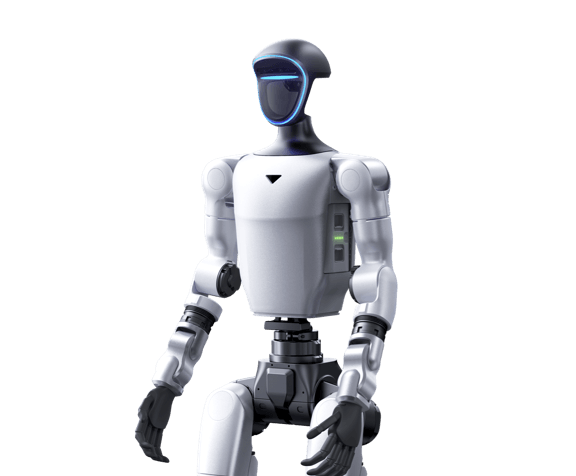
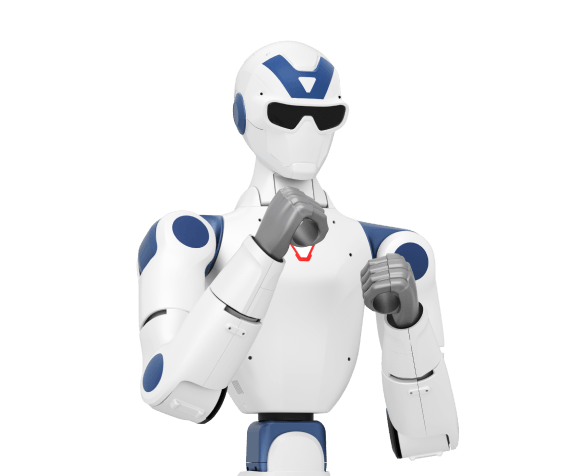
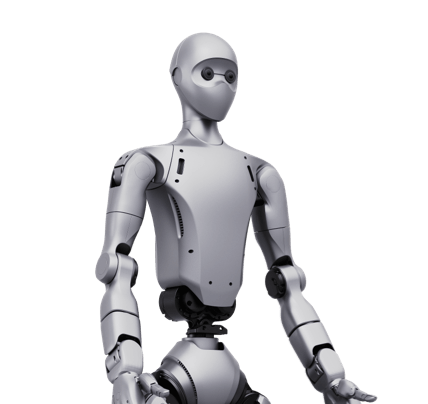
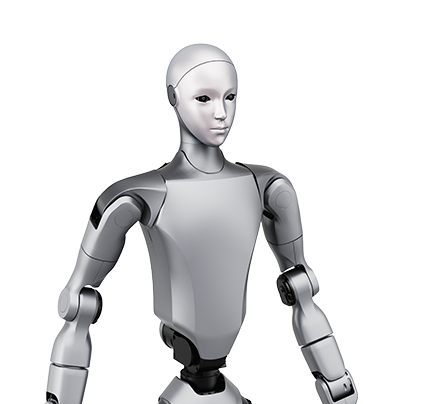
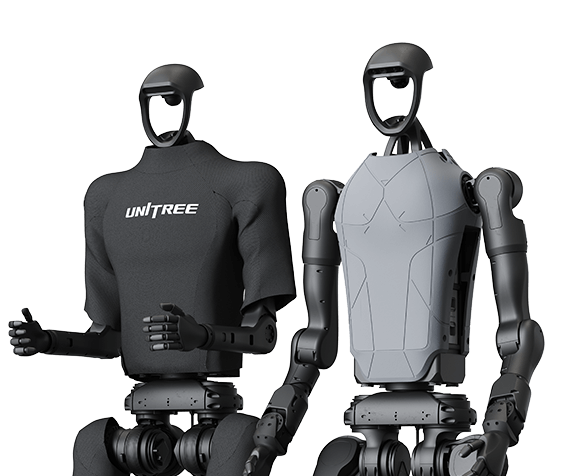
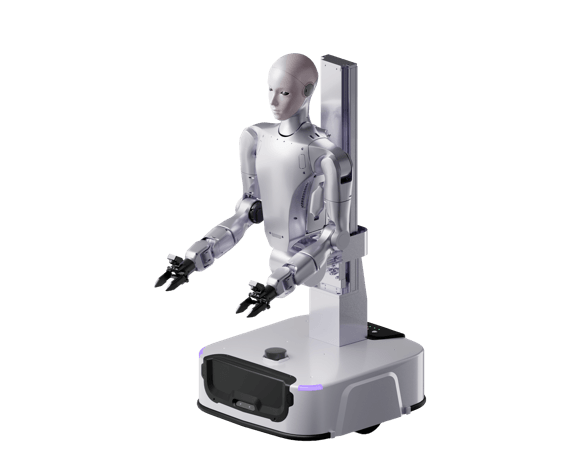
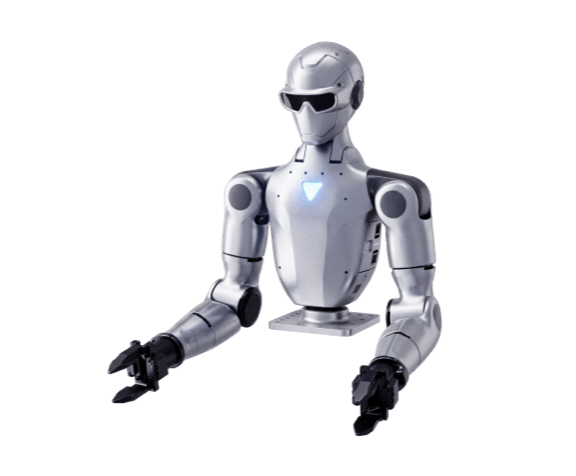
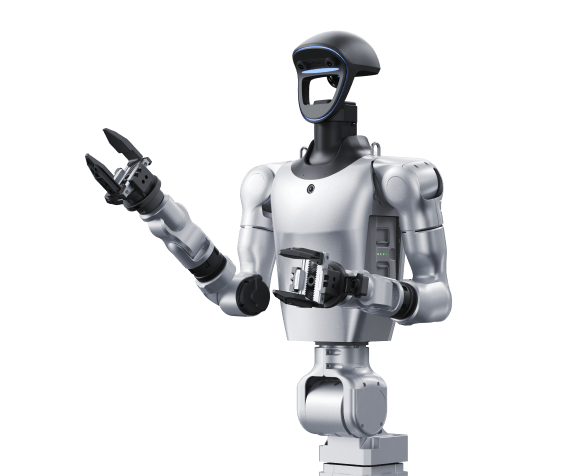
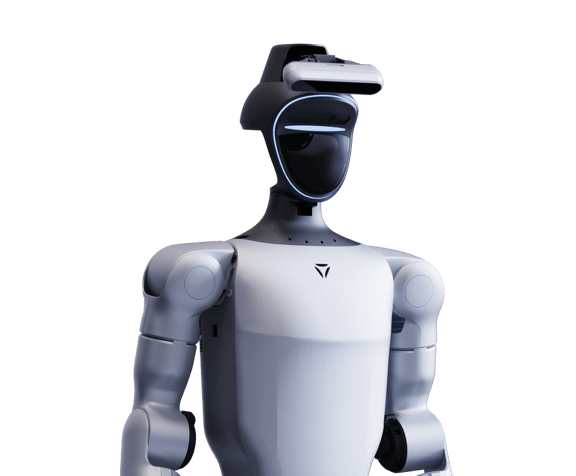
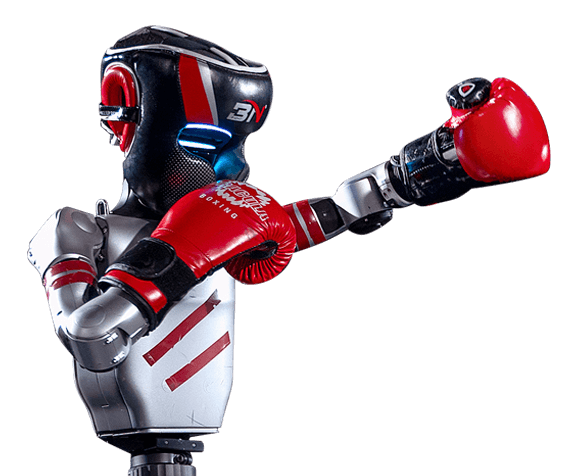
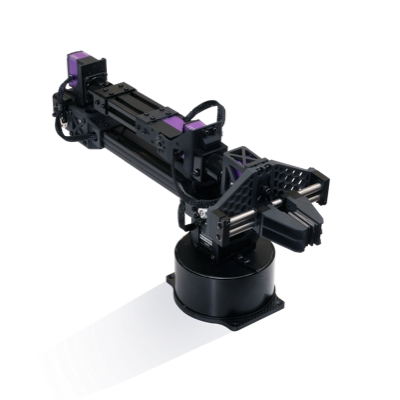
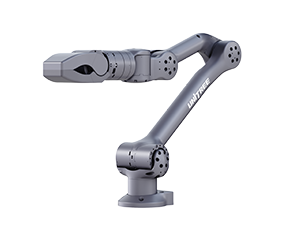
Unitree Humanoid Robots
Full-Stack Solution for Embodied
Data Collection and Training
Turn Real-World Task Data into Deployable Robot Capabilities Faster
Contact Sales →
High-Quality Real-World Data Determines Whether Robots Can Enter the Real World
Embodied AI robots must continually learn in real physical environments, developing an understanding of the world through perception, action, and feedback. High-quality, diverse data is the essential foundation for advancing robot capabilities and iteratively improving models.
Insufficient High-Quality Demonstration Data
High-quality interaction data is difficult to obtain in complex physical environments, making it challenging to continuously build training datasets that cover multiple tasks and scenarios.
Lack of Embodied Data Collection Workflow Management
Collection equipment, task workflows, and data management lack support from a unified platform. Fragmented workflows and heavy reliance on manual effort make large-scale, standardized, sustainable data production difficult.
Low Efficiency in Converting Data into Models
Disconnected data processing, model training, and deployment workflows, together with the lack of an efficient training and inference toolchain, hinder rapid data-to-model conversion and continuous iteration of robot capabilities.
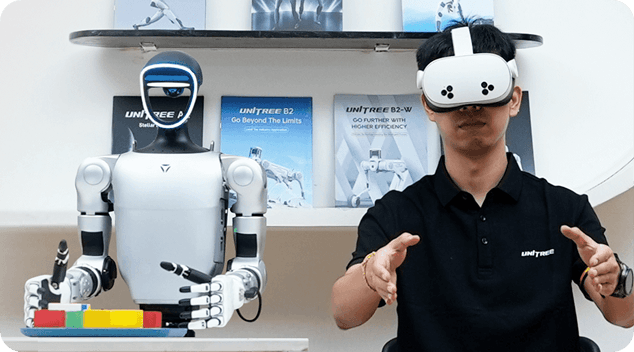
High-Precision Teleoperation Interface
Enables remote interaction between people and robots, providing an operator interface for robot task execution and embodied data collection.
Learn More
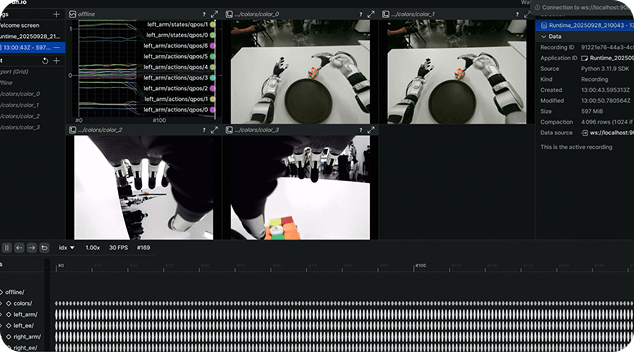
Systematic Embodied Data Collection Tools
An intelligent, one-stop platform covering the entire workflow, including embodied data collection, processing, annotation, review, and data asset management.
Learn More
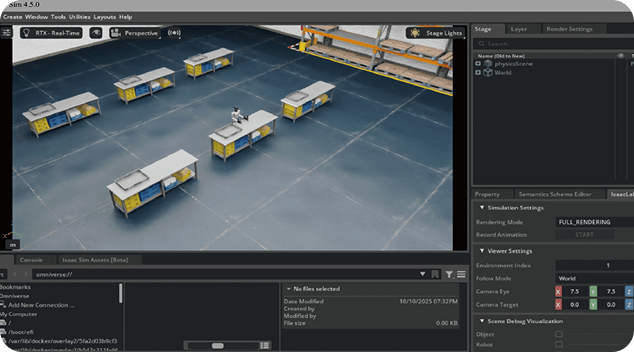
Comprehensive Model Training and Inference Tools
Supports distributed model training, custom model development and deployment, and compatibility with mainstream open-source model frameworks.
Learn More
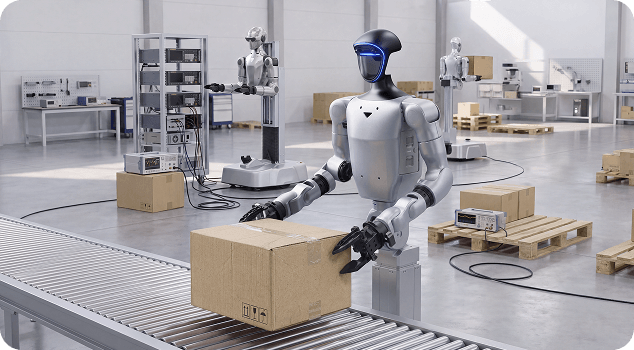
High-Performance Humanoid Robot Platforms
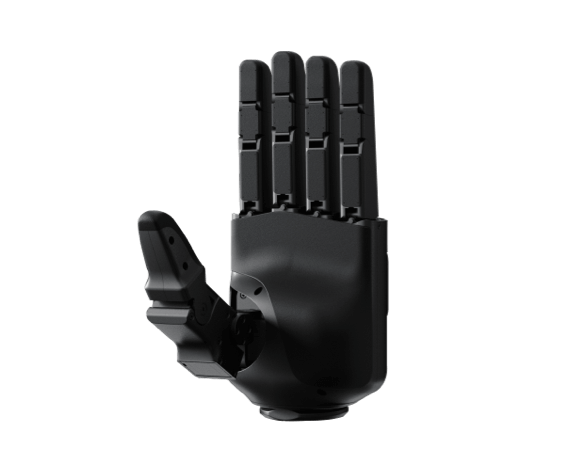
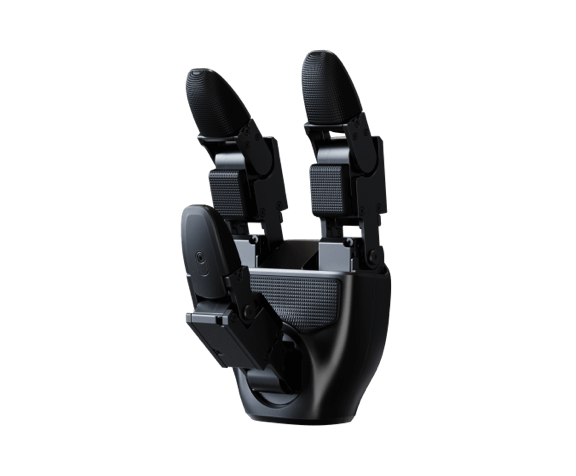
Multiple types of in-house-developed humanoid robot platforms integrate proprietary motors, reducers, encoders, and a range of robot sensors to meet task requirements across robot form factors.
Learn More
High-Precision Teleoperation Interface
Through low-latency, high-precision full-body motion interaction, it enables real-time remote control of robots and provides a stable and reliable operational entry point for embodied data collection.
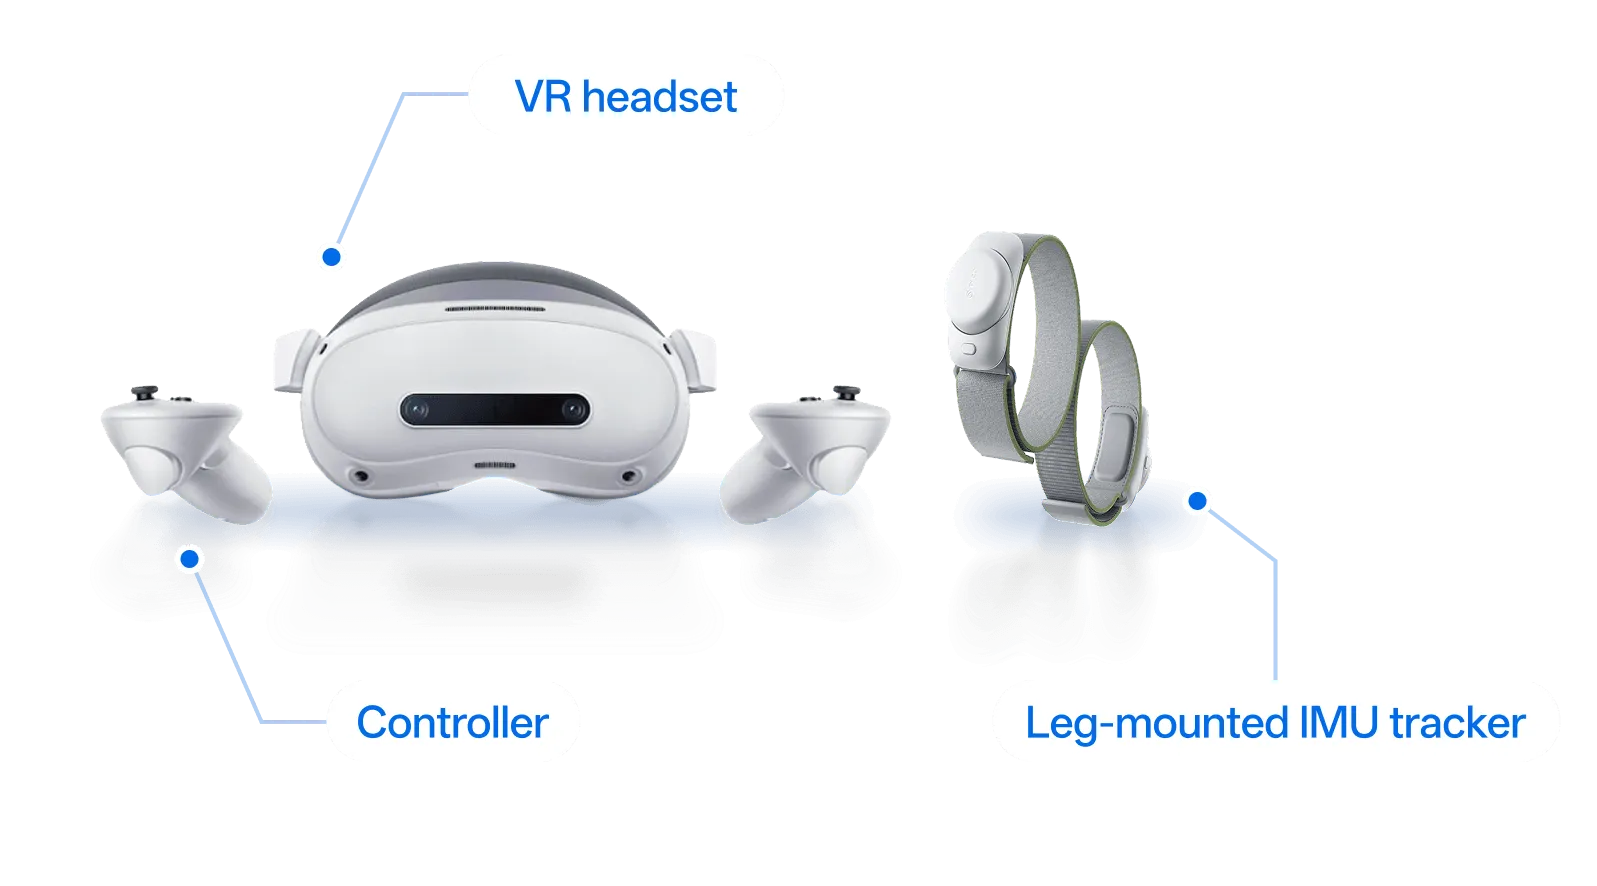
Low-Latency Control Response
Through a low-latency control link, it enables real-time transmission of operation commands and rapid response of robot movements, ensuring synchronized human-robot movements and improving teleoperation smoothness for complex tasks.
High-Precision Full-Body Motion Mapping
It fully captures the operator's upper-limb operations and lower-limb movement states and precisely maps them to the robot's full-body joints, achieving high-fidelity, highly consistent motion reproduction.
Synchronized Multimodal Embodied Data Collection
During teleoperation, it synchronously collects multidimensional information such as first-person-view visual data, pose, environmental perception, and robot state, forming complete demonstration data covering the scene, behavior, and control commands.
- < 100ms
System response latency
Approx. 20msFull-body motion capture latency
- 60Hz
Embodied data collection frequency
≤ 5cmAverage position error
≤ 6°angular error
- 200Hz
Motion tracking frequency
≥ 98%Stepping detection accuracy
Systematic Embodied Data Collection Tools
Through standardized processes and reconfigurable scenarios, it improves the efficiency of scenario-based embodied data collection and reduces the cost of traditional collection methods.
Visual Template Management for Efficient Data Collection
Integrating project management, task assignment, progress tracking, and status analysis, it uses template-based configuration to generate embodied data collection tasks with one click, tracks status in real time throughout the process, enables smoother collaboration, and improves collection efficiency.
Flexible Configuration of Diverse Robot Platforms and Data Collection End Effectors
With “diverse compatibility” as its core design principle, it supports embodied data collection with diverse robot and end-effector configurations and provides strong data standardization capabilities, ensuring end-to-end connectivity from diverse devices to high-quality model training data.
Scalable Multi-Robot Collaborative Data Collection
It provides the technical capability to support multiple robots conducting embodied data collection synchronously. Through a high-concurrency architecture and load-balanced scheduling, it ensures real-time reception and processing of massive data streams, laying the foundation for building high-quality datasets.
Stable, Reliable Online Data Collection
Built on a highly available service architecture, the platform offers strong format compatibility; data can be directly output or converted into various mainstream training formats, improving R&D efficiency.
1
Task design
2
Embodied data collection
3
Quality control
4
Data asset management
5
Training-format delivery
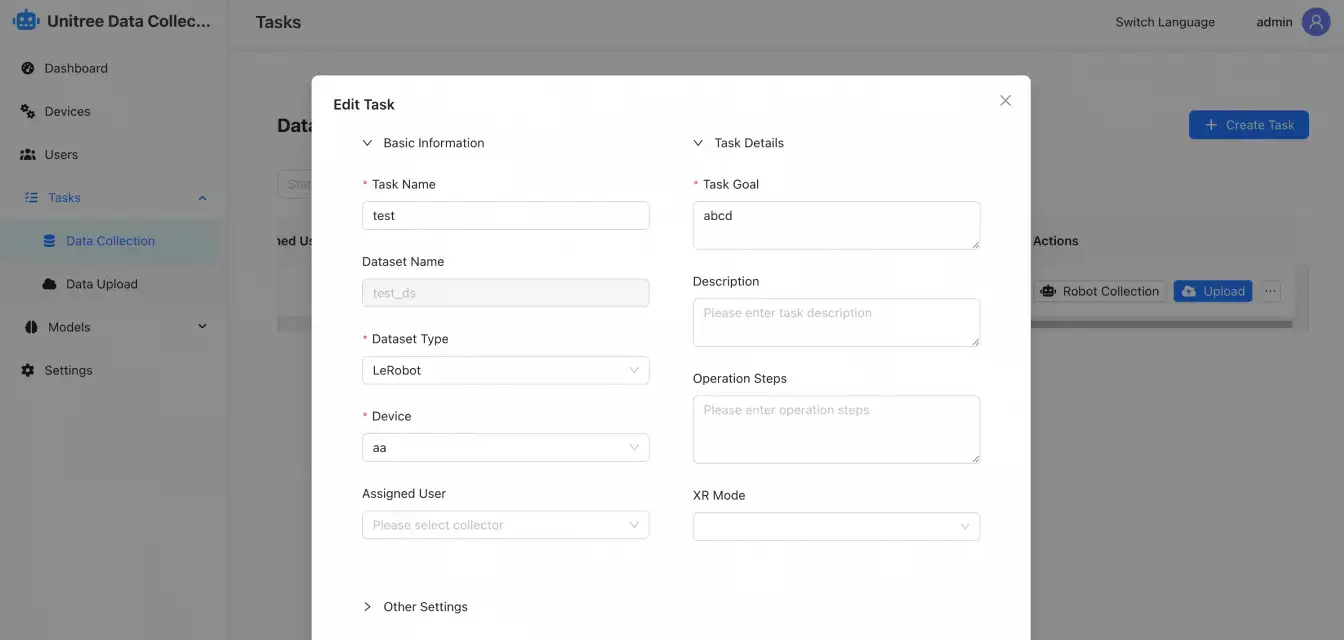
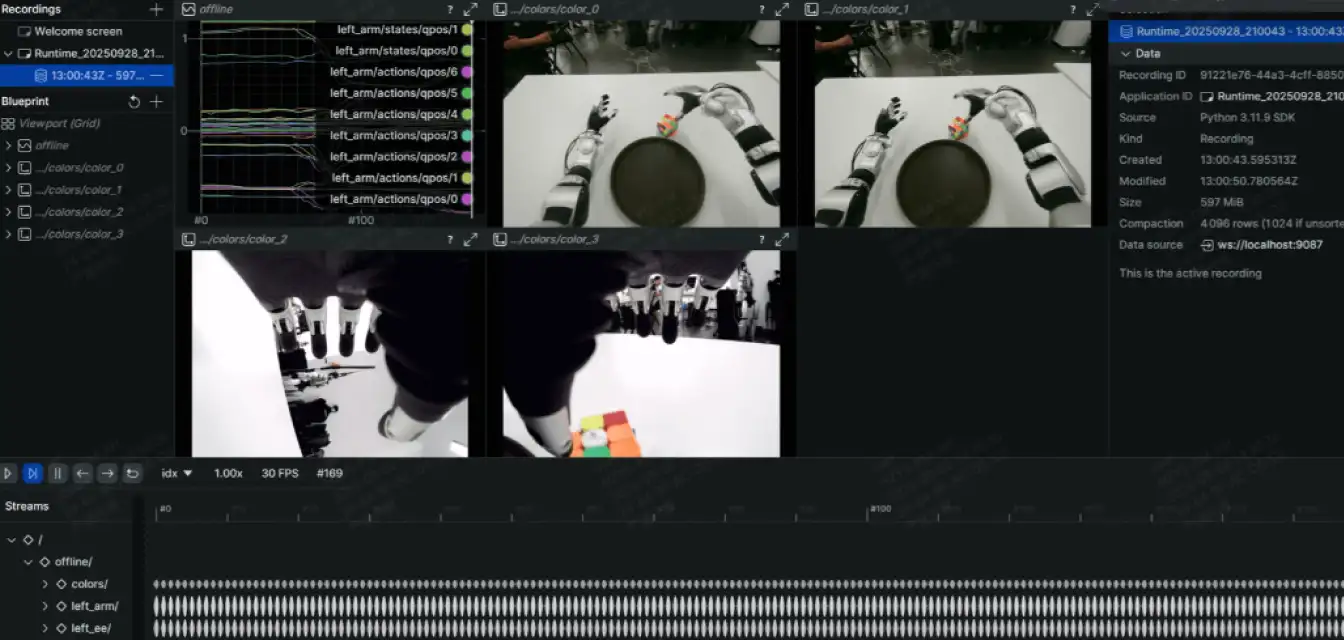
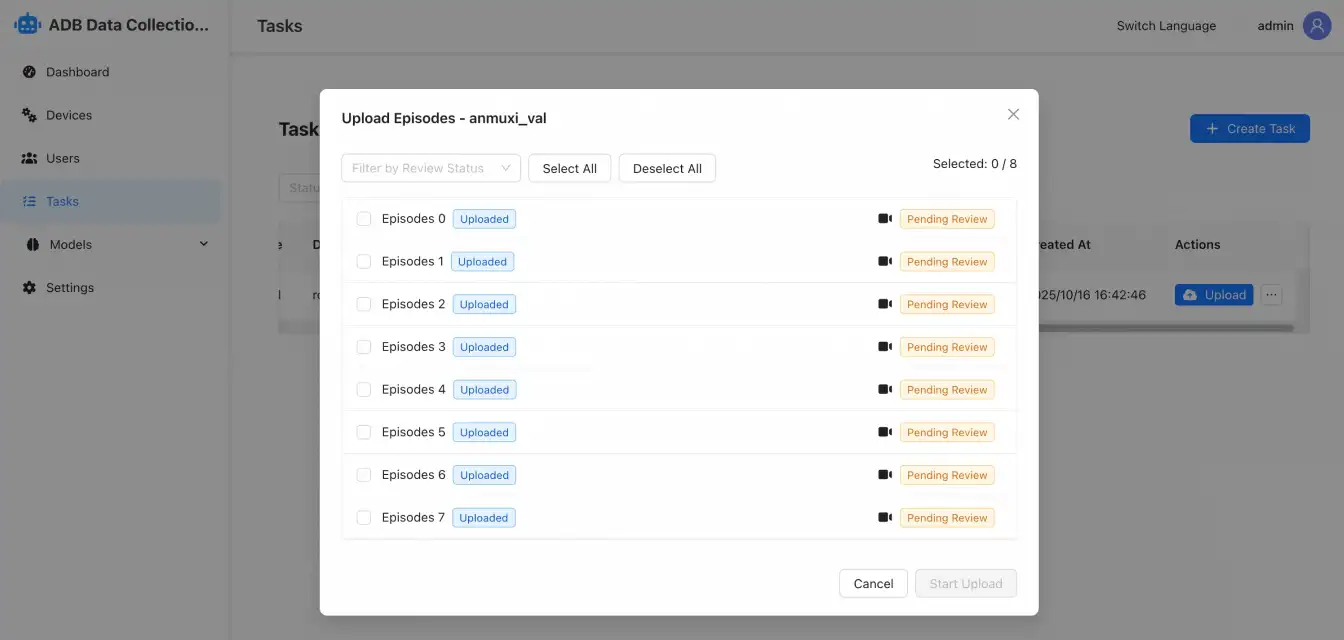
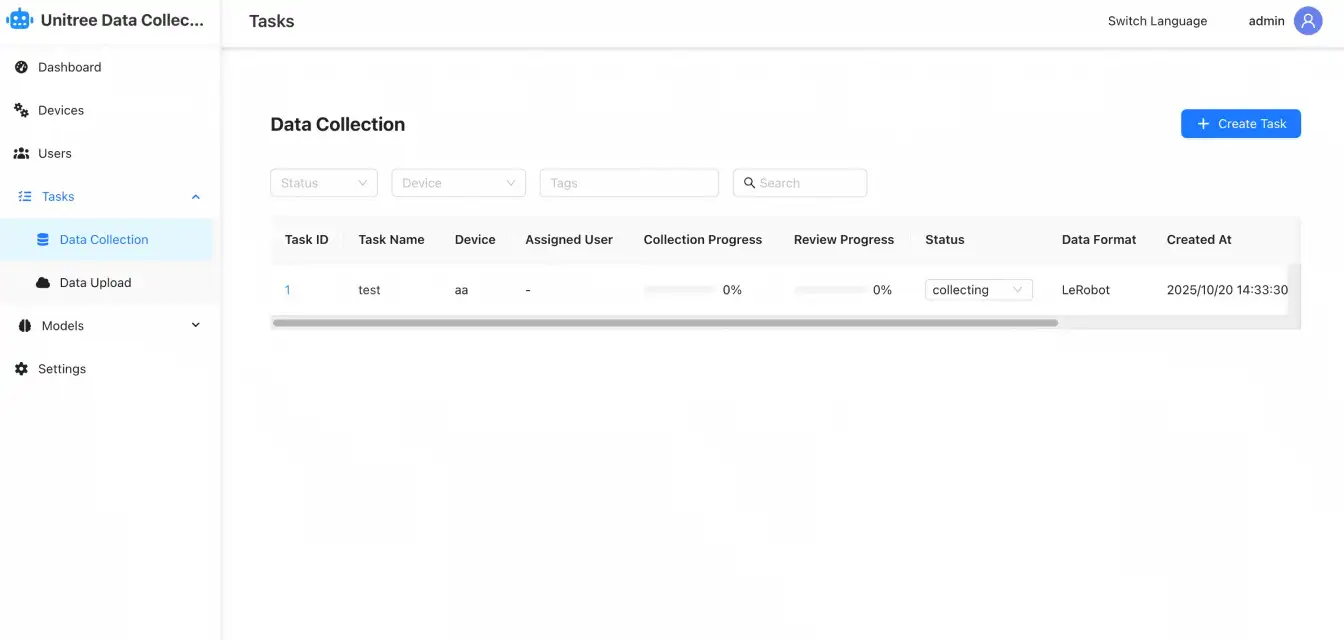
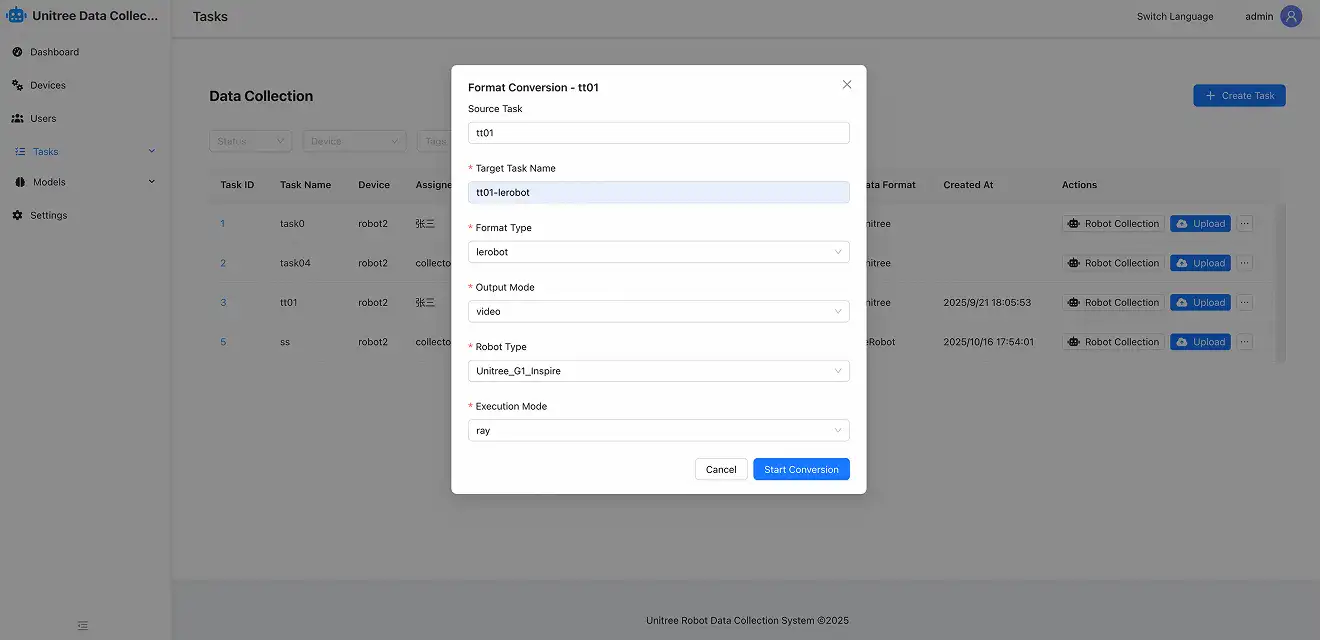
Task design
Establish repeatable task templates and collection standards;
Comprehensive Model Training and Inference Tools
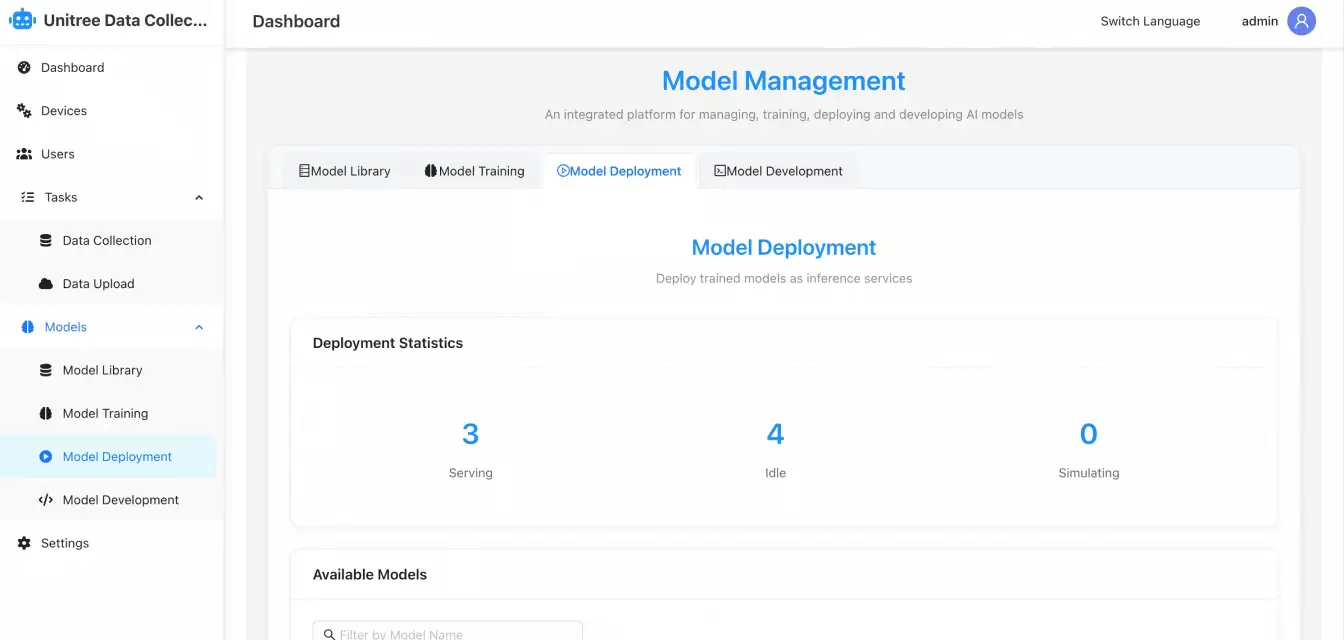
It supports workflows from data processing through model training,simulation evaluation,and one-click deployment. The platform seamlessly integrates multiple mainstream open-source robot model frameworks, enabling developers to efficiently complete the entire R&D and deployment process on a unified platform.
A Rich Ecosystem Supporting Mainstream Models
It builds an open model ecosystem with built-in community datasets, supports training on open-source datasets, and deeply integrates open-source models such as PI, GR00T, and Unitree UnifoLM.
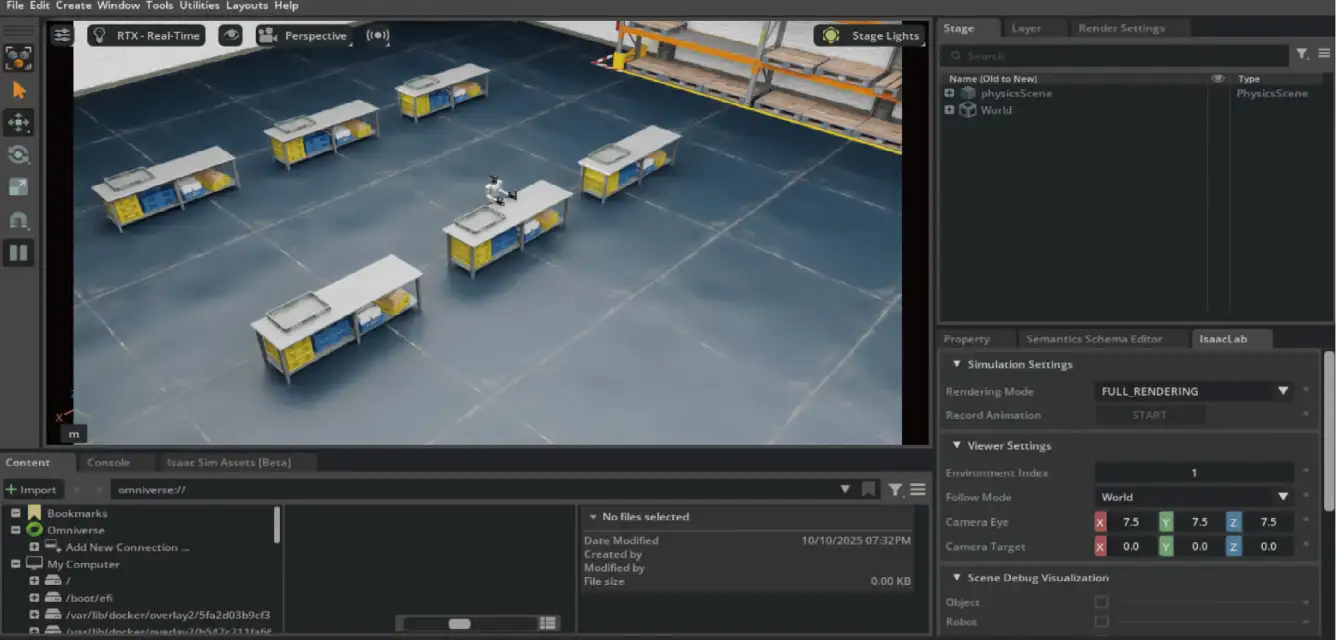
Simulation Environments for Model Evaluation
It includes a high-fidelity, high-precision 3D asset library and rapidly generates comprehensive evaluation plans by building simulation environments, providing support for algorithm validation.
Easy to Use, Quick to Deploy
Ready to use out of the box, it quickly starts model development through “one-click training” and uses integrated simulation tools for reliable evaluation, ultimately enabling seamless migration of algorithms to real robots.
Distributed Training for High Performance
Built on a high-performance distributed training architecture, the platform supports elastic scheduling and parallel acceleration of compute tasks, scales resources dynamically with workload, and achieves 90% GPU utilization.
1
Model architecture selection
2
Training configuration
3
Real-time monitoring
4
Parameter optimization
5
Simulation testing
6
Model export and deployment
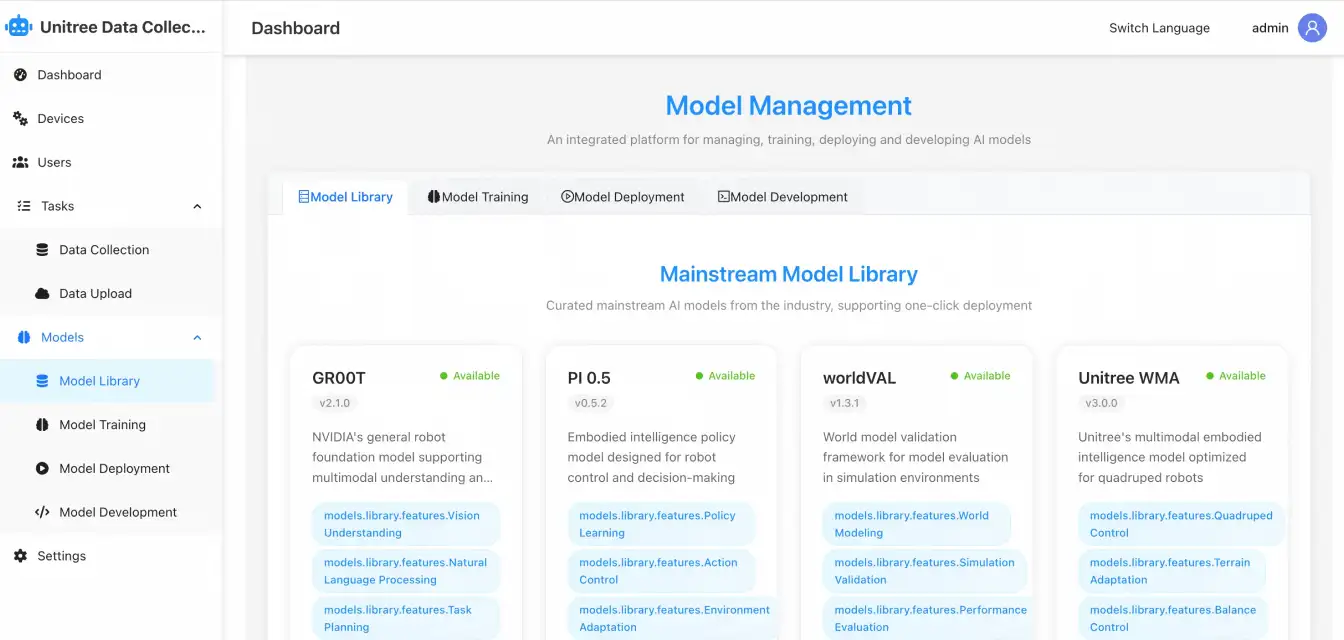
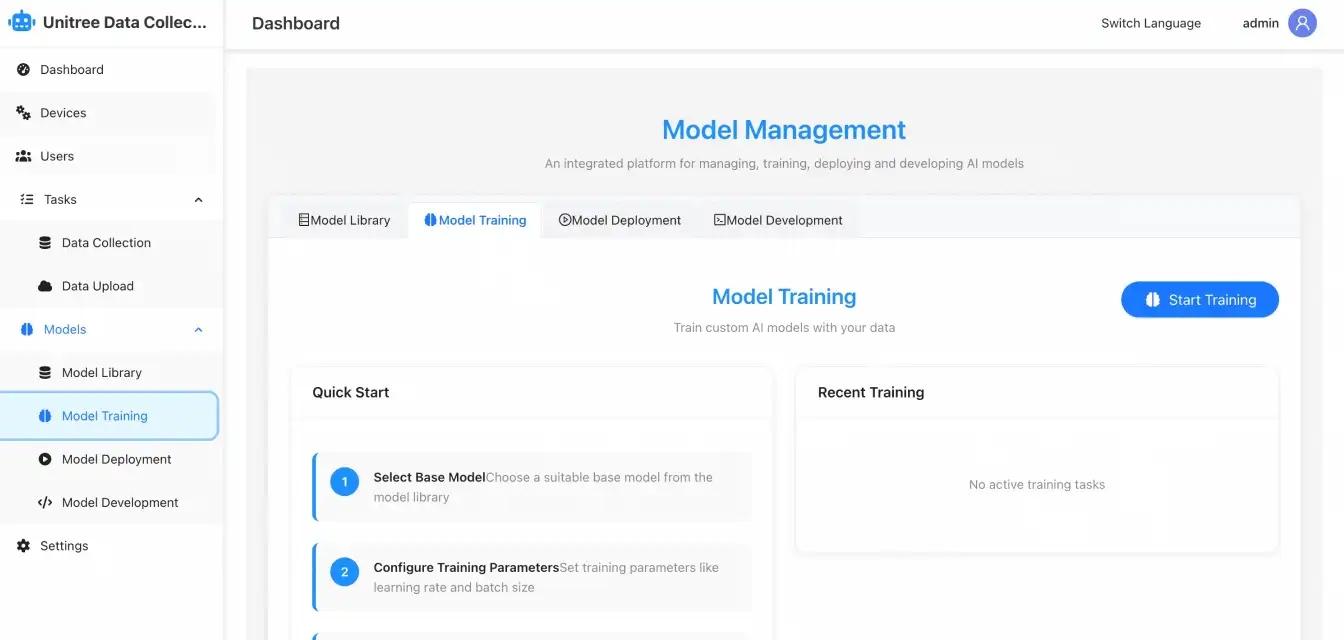
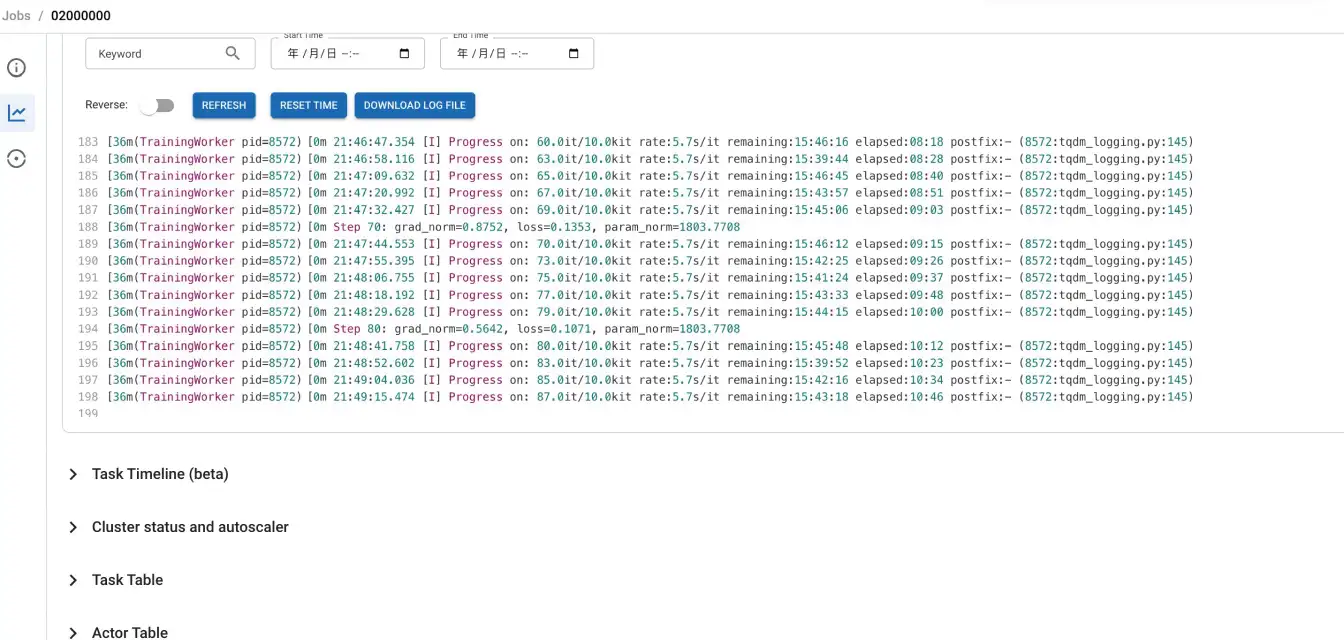
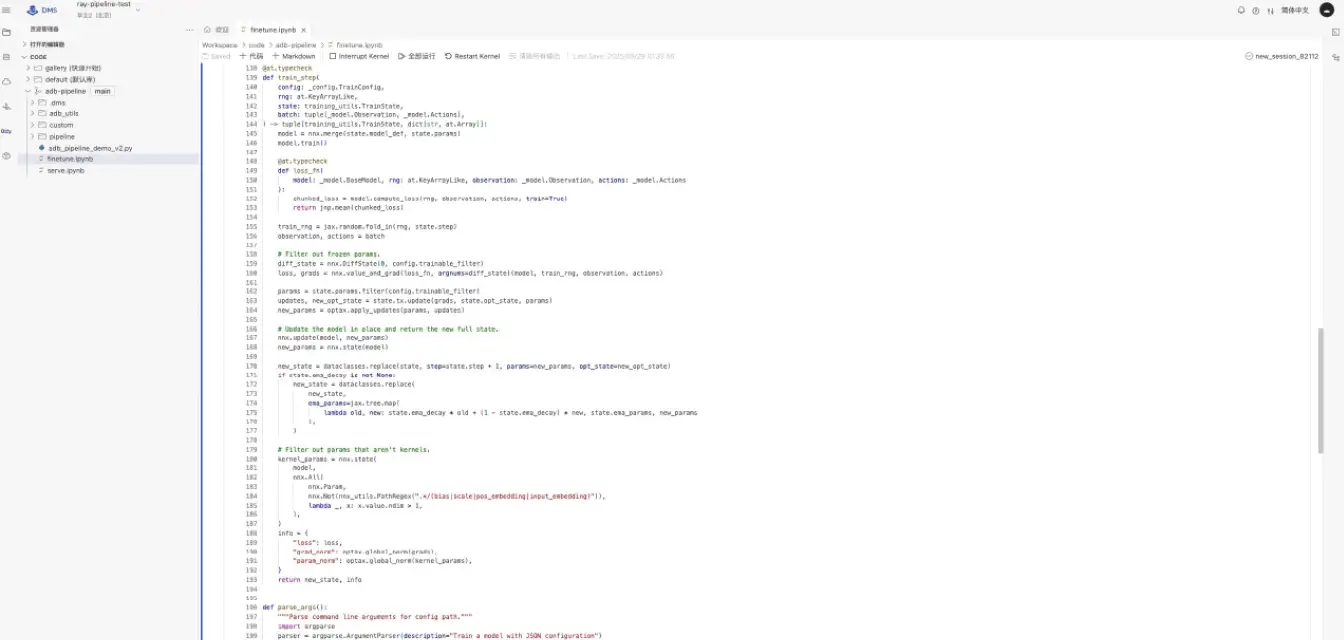
Model architecture selection
Select the model architecture and technical approach suited to the task.
High-Performance Humanoid Robot Platforms
G1 Series
A highly agile humanoid robot platform for embodied intelligence research exploration, commercial application validation
R1 Series
A lightweight humanoid robot platform for embodied intelligence algorithm validation, teaching and hands-on training, and commercial
H2 Series
A full-size humanoid robot platform for precision industrial operations and intelligent manufacturing.
H2-X Series
A new generation of full-size humanoid robots, designed for demanding and complex industrial applications.
G1
Full-body motion with a high number of degrees of freedom, dexterous manipulation, multimodal perception, and open development.
Product Parameters
Overall Dimensions
1340×450×200 mm
Overall Weight
Approx. 35kg
Total Degrees of Freedom (Excluding End Effectors)
23~25
Maximum Arm Payload
3~4 kg
Battery Runtime
Approx. 2h
Perception Sensors
Stereo Camera + Chest-Mounted Wide-Angle Camera + 3D LiDAR
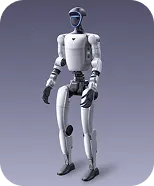
G1
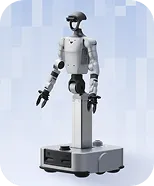
G1-A / G1-D
G1-A / G1-D
Multi-form-factor task deployment, operation across an expanded workspace, and stable, continuous execution.
Product Parameters
Overall Dimensions
Approx. 635×450×200 mm ~ 1680×620×620 mm
Overall Weight
Approx. 22~90 kg
Total Degrees of Freedom (Excluding End Effectors)
19~21
Maximum Arm Payload
3 kg
垂直作业空间
0~2 m
Battery Runtime
Approx. 2~6 h
Perception Sensors
Stereo Camera + Chest-Mounted Wide-Angle Camera;
The Flagship Version’s base is equipped with LiDAR, depth cameras, and safety sensors.
G1
G1-A / G1-D
Configuration Module
 Multi-Form-Factor Robot Platforms
 Full-Body Teleoperation Kit
 High-Performance Private Embodied Data Collection Platform
 Compute Server
 Model Training Capabilities
200+
Task Datasets
(covering different end effectors and tasks)
4
Training Algorithms
(ACT, PI0.5, PI0, and GR00T)
7
UnifoLM foundation models
10+
Demos
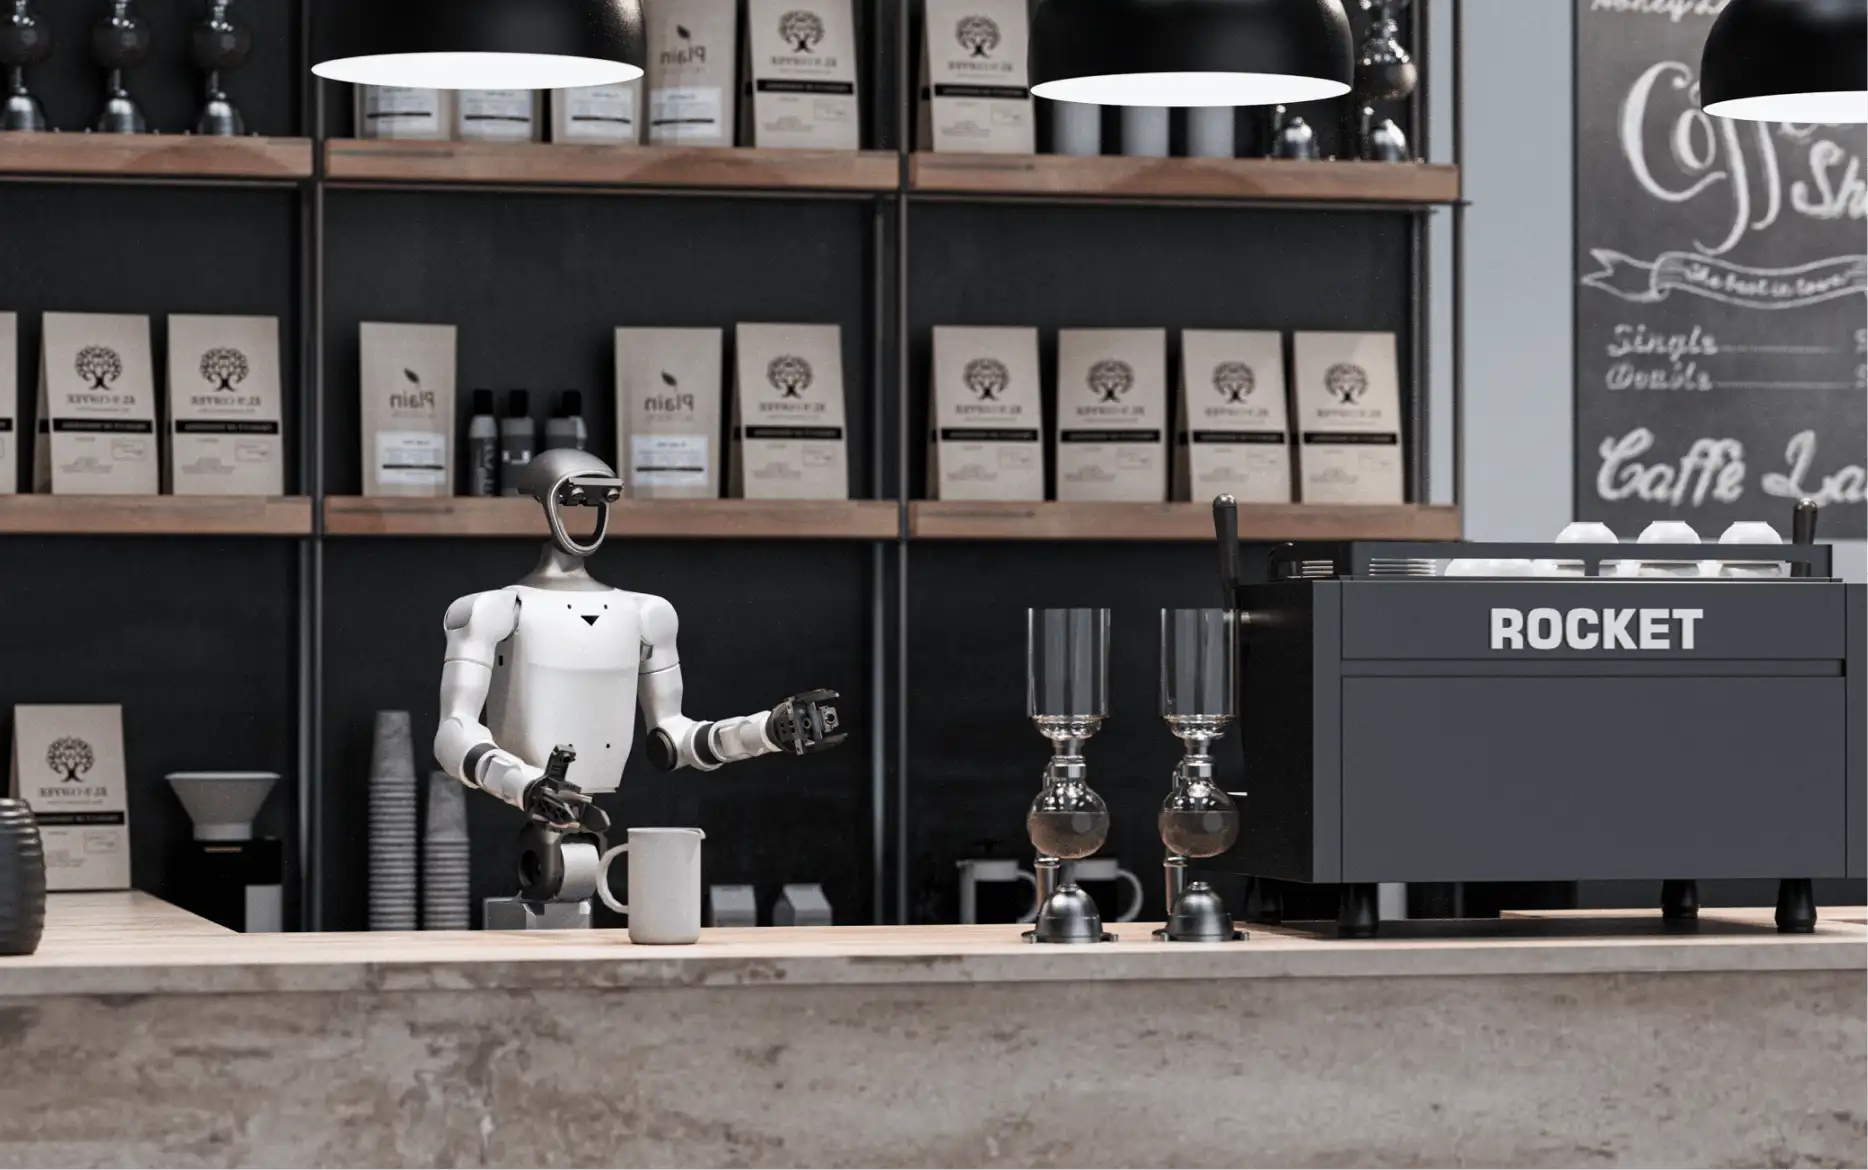
- Business serivce
- Housework
- Education and reserch
- Industrial application
- Contact Sales:+86 17621781139
- Contact Team:sales_global@unitree.com
- Contact Address:China Digital Valley Building, No. 276 Wulianwang Street, Binjiang District, Hangzhou City, Zhejiang Province, P.R.China